
Products / Robot Arms / OpenArm
OYMOTION
OpenArm
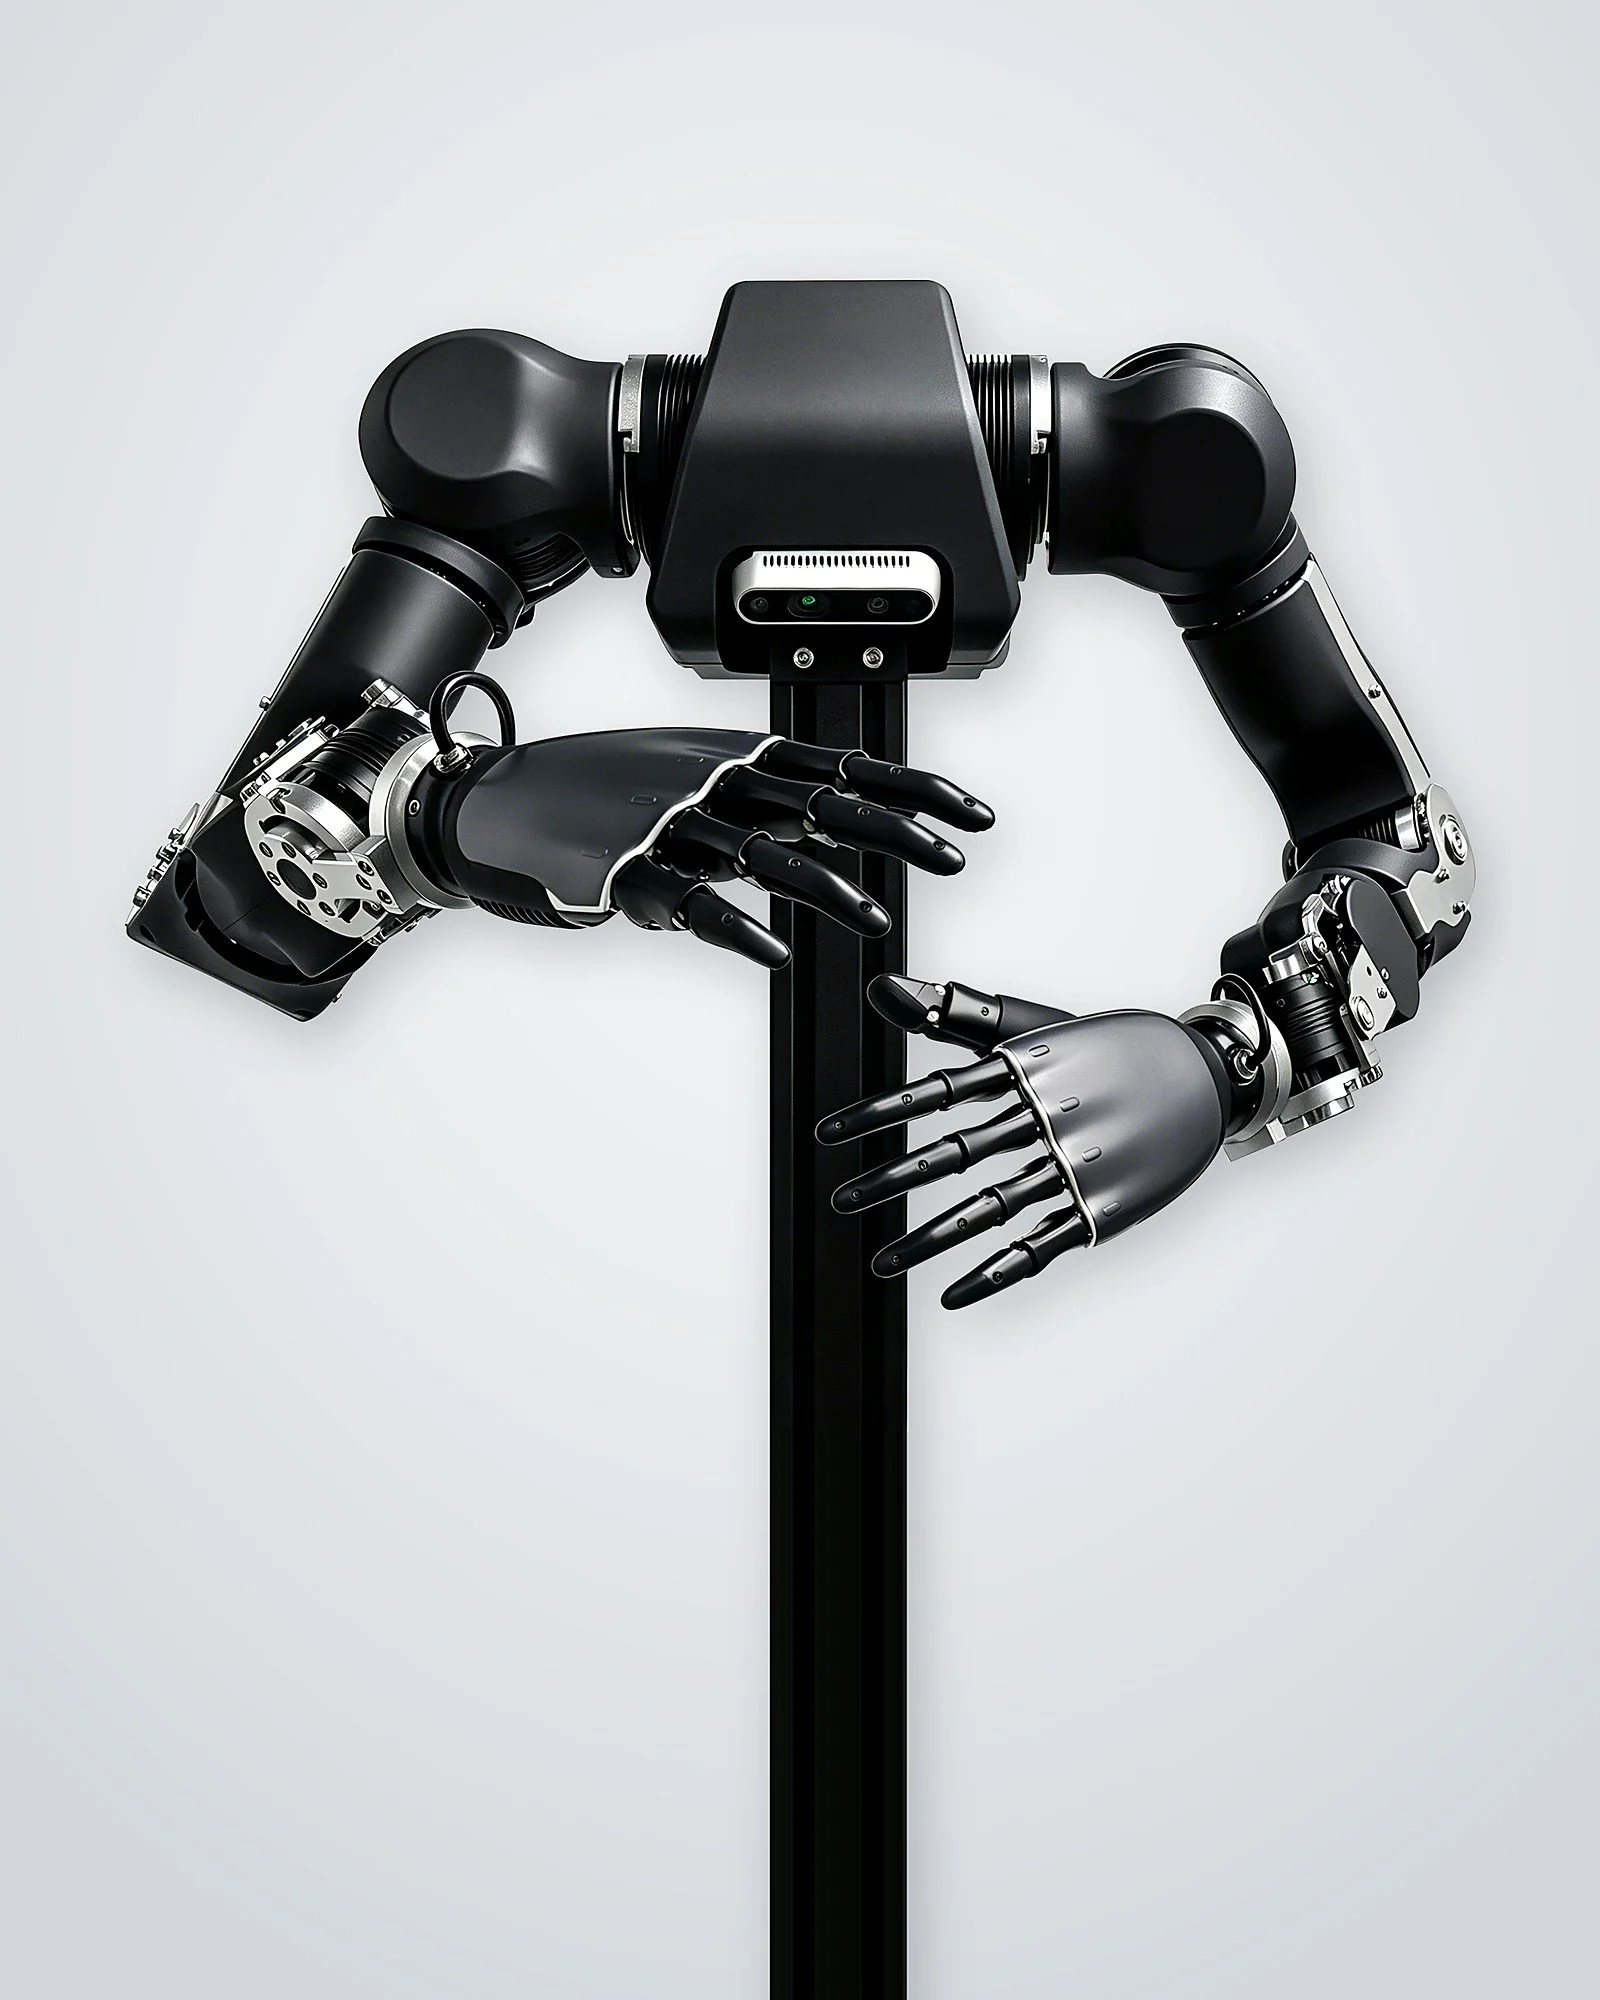
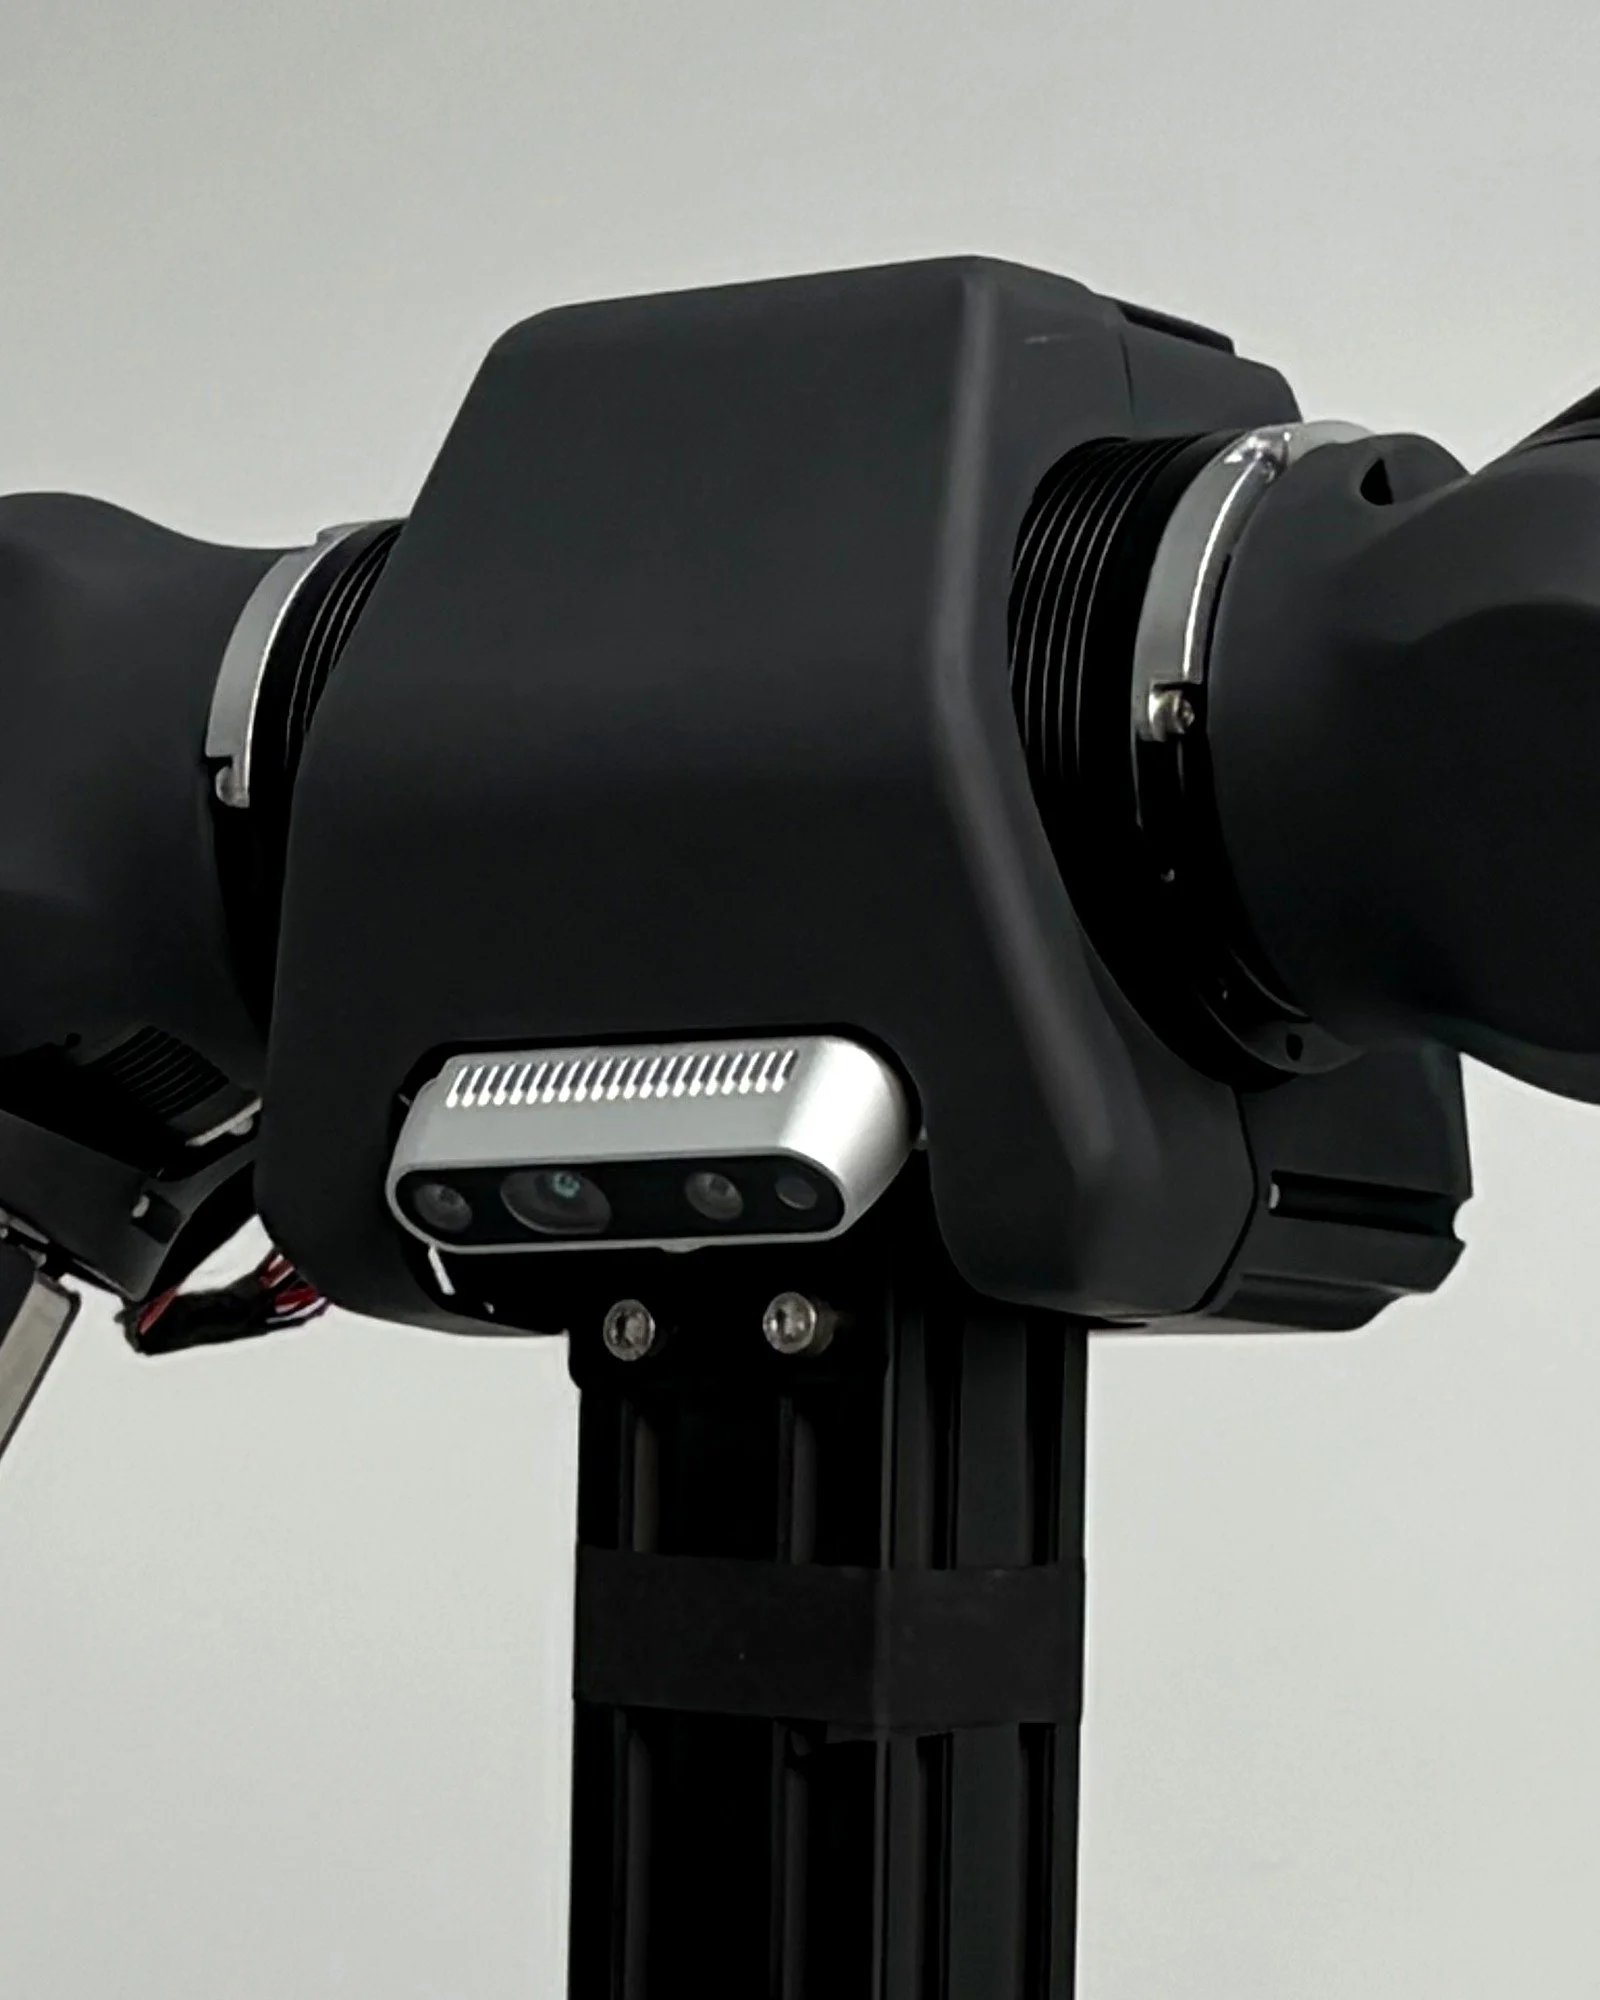
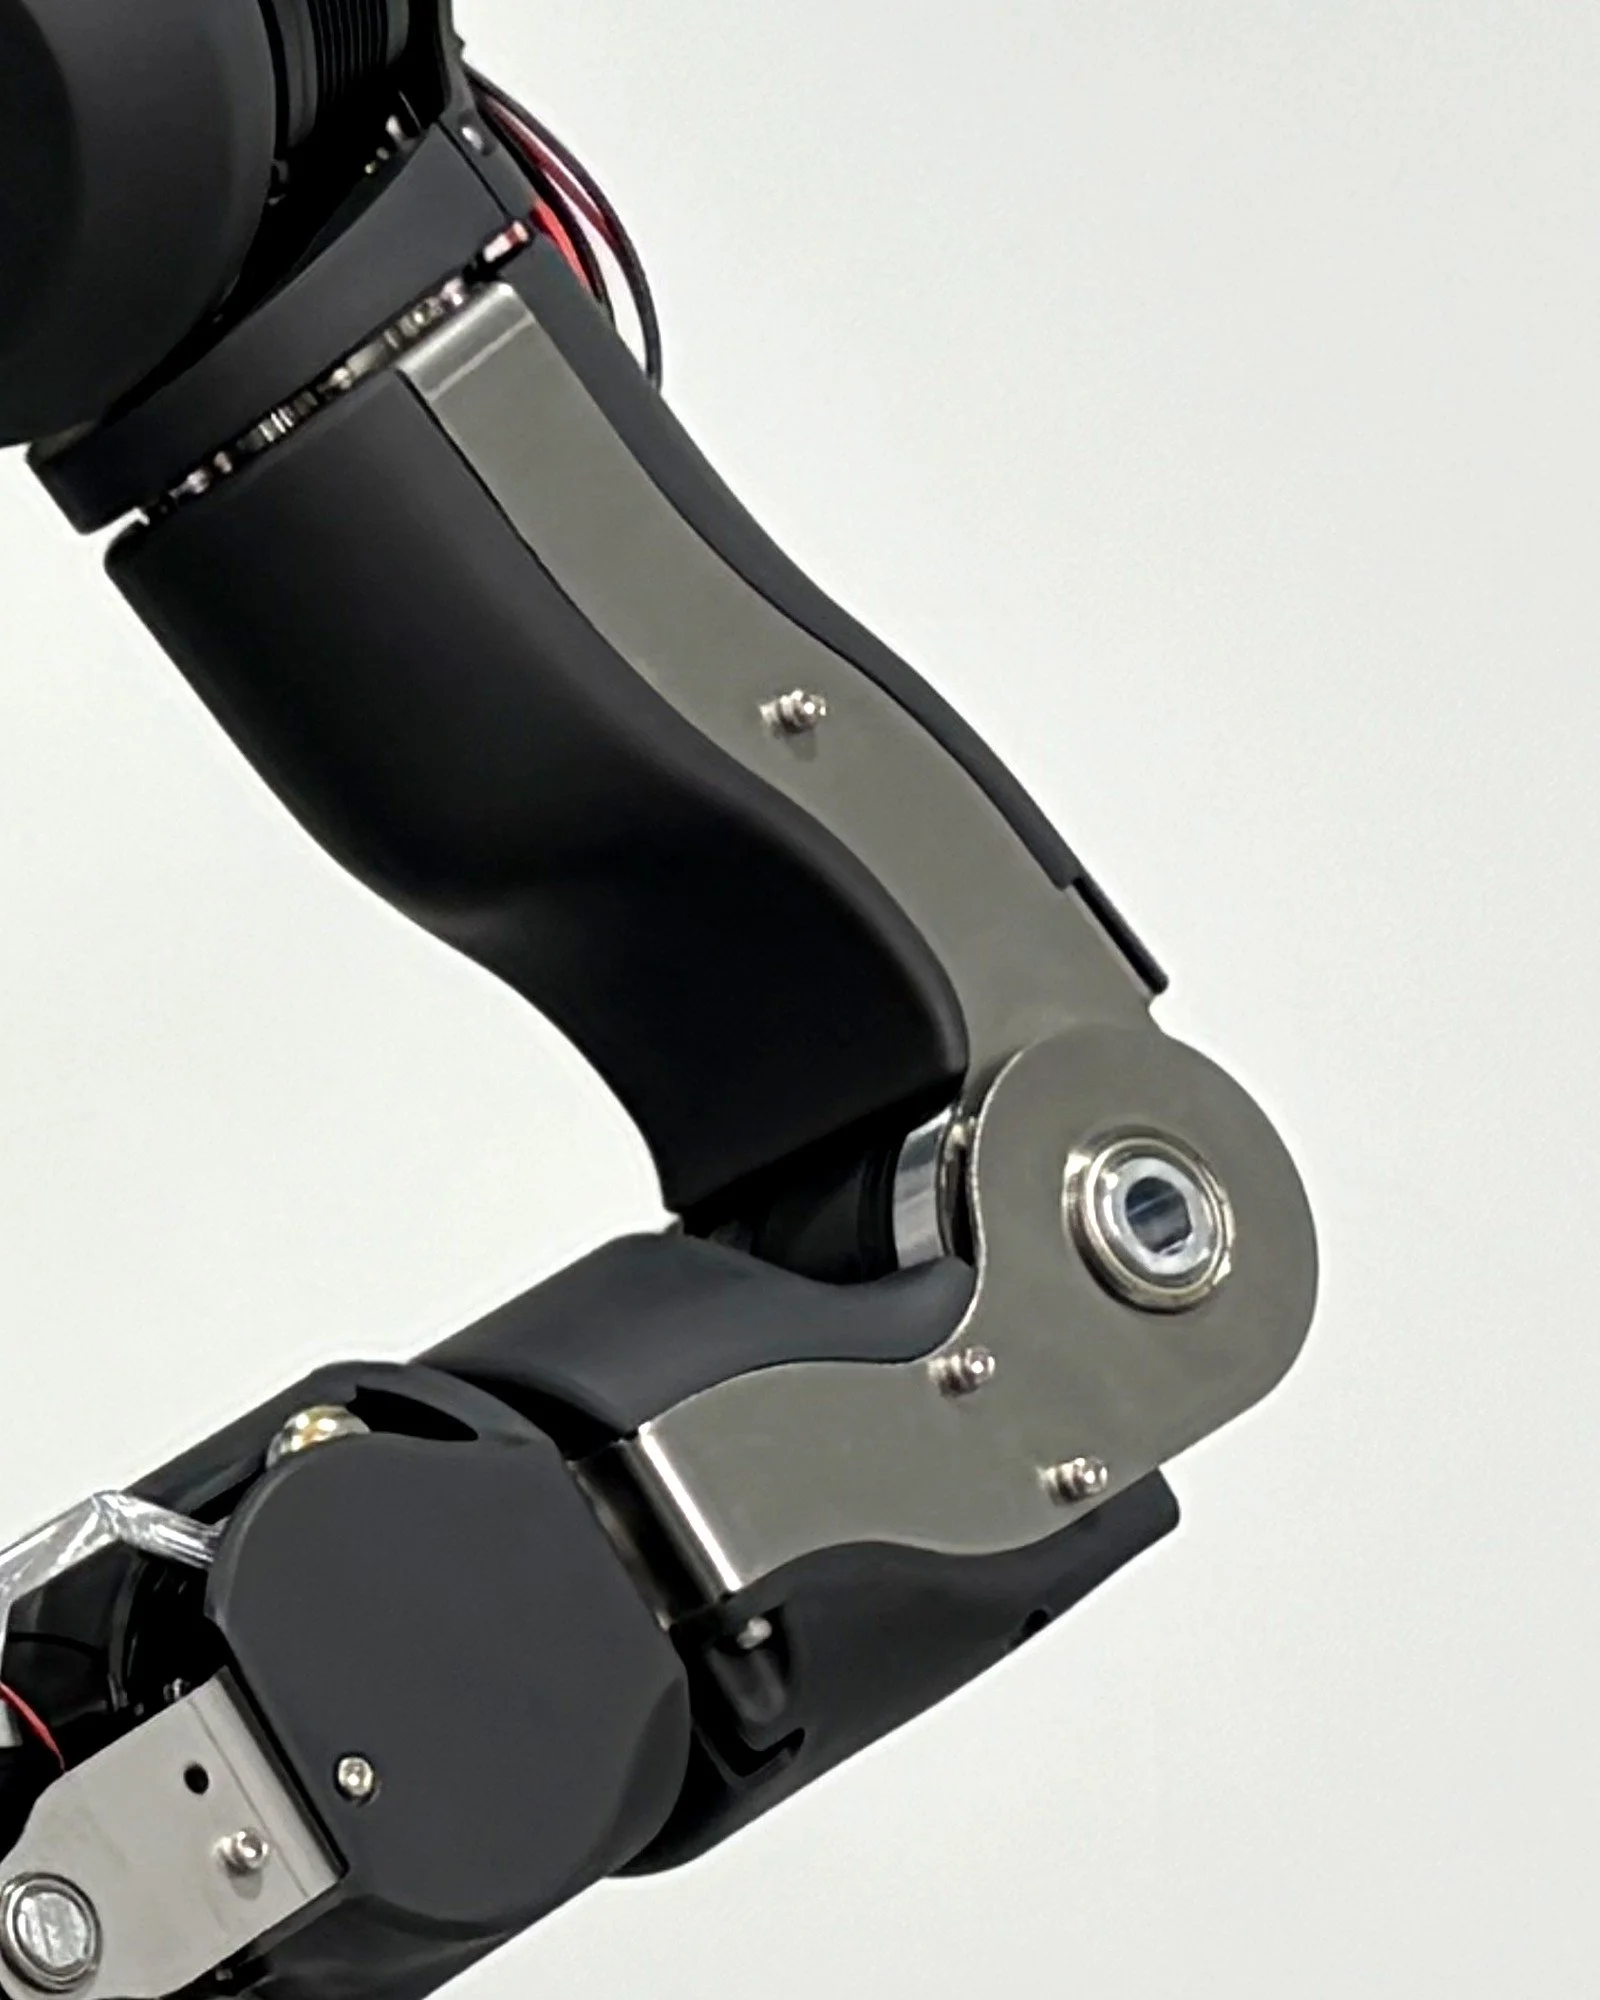
Embodied dual-arm robot with Dexterous Robotic Hand
A dual-arm platform for teleoperation, motion data collection and embodied AI research, combining 7-DoF arms with dexterous hands and force feedback.
Description:
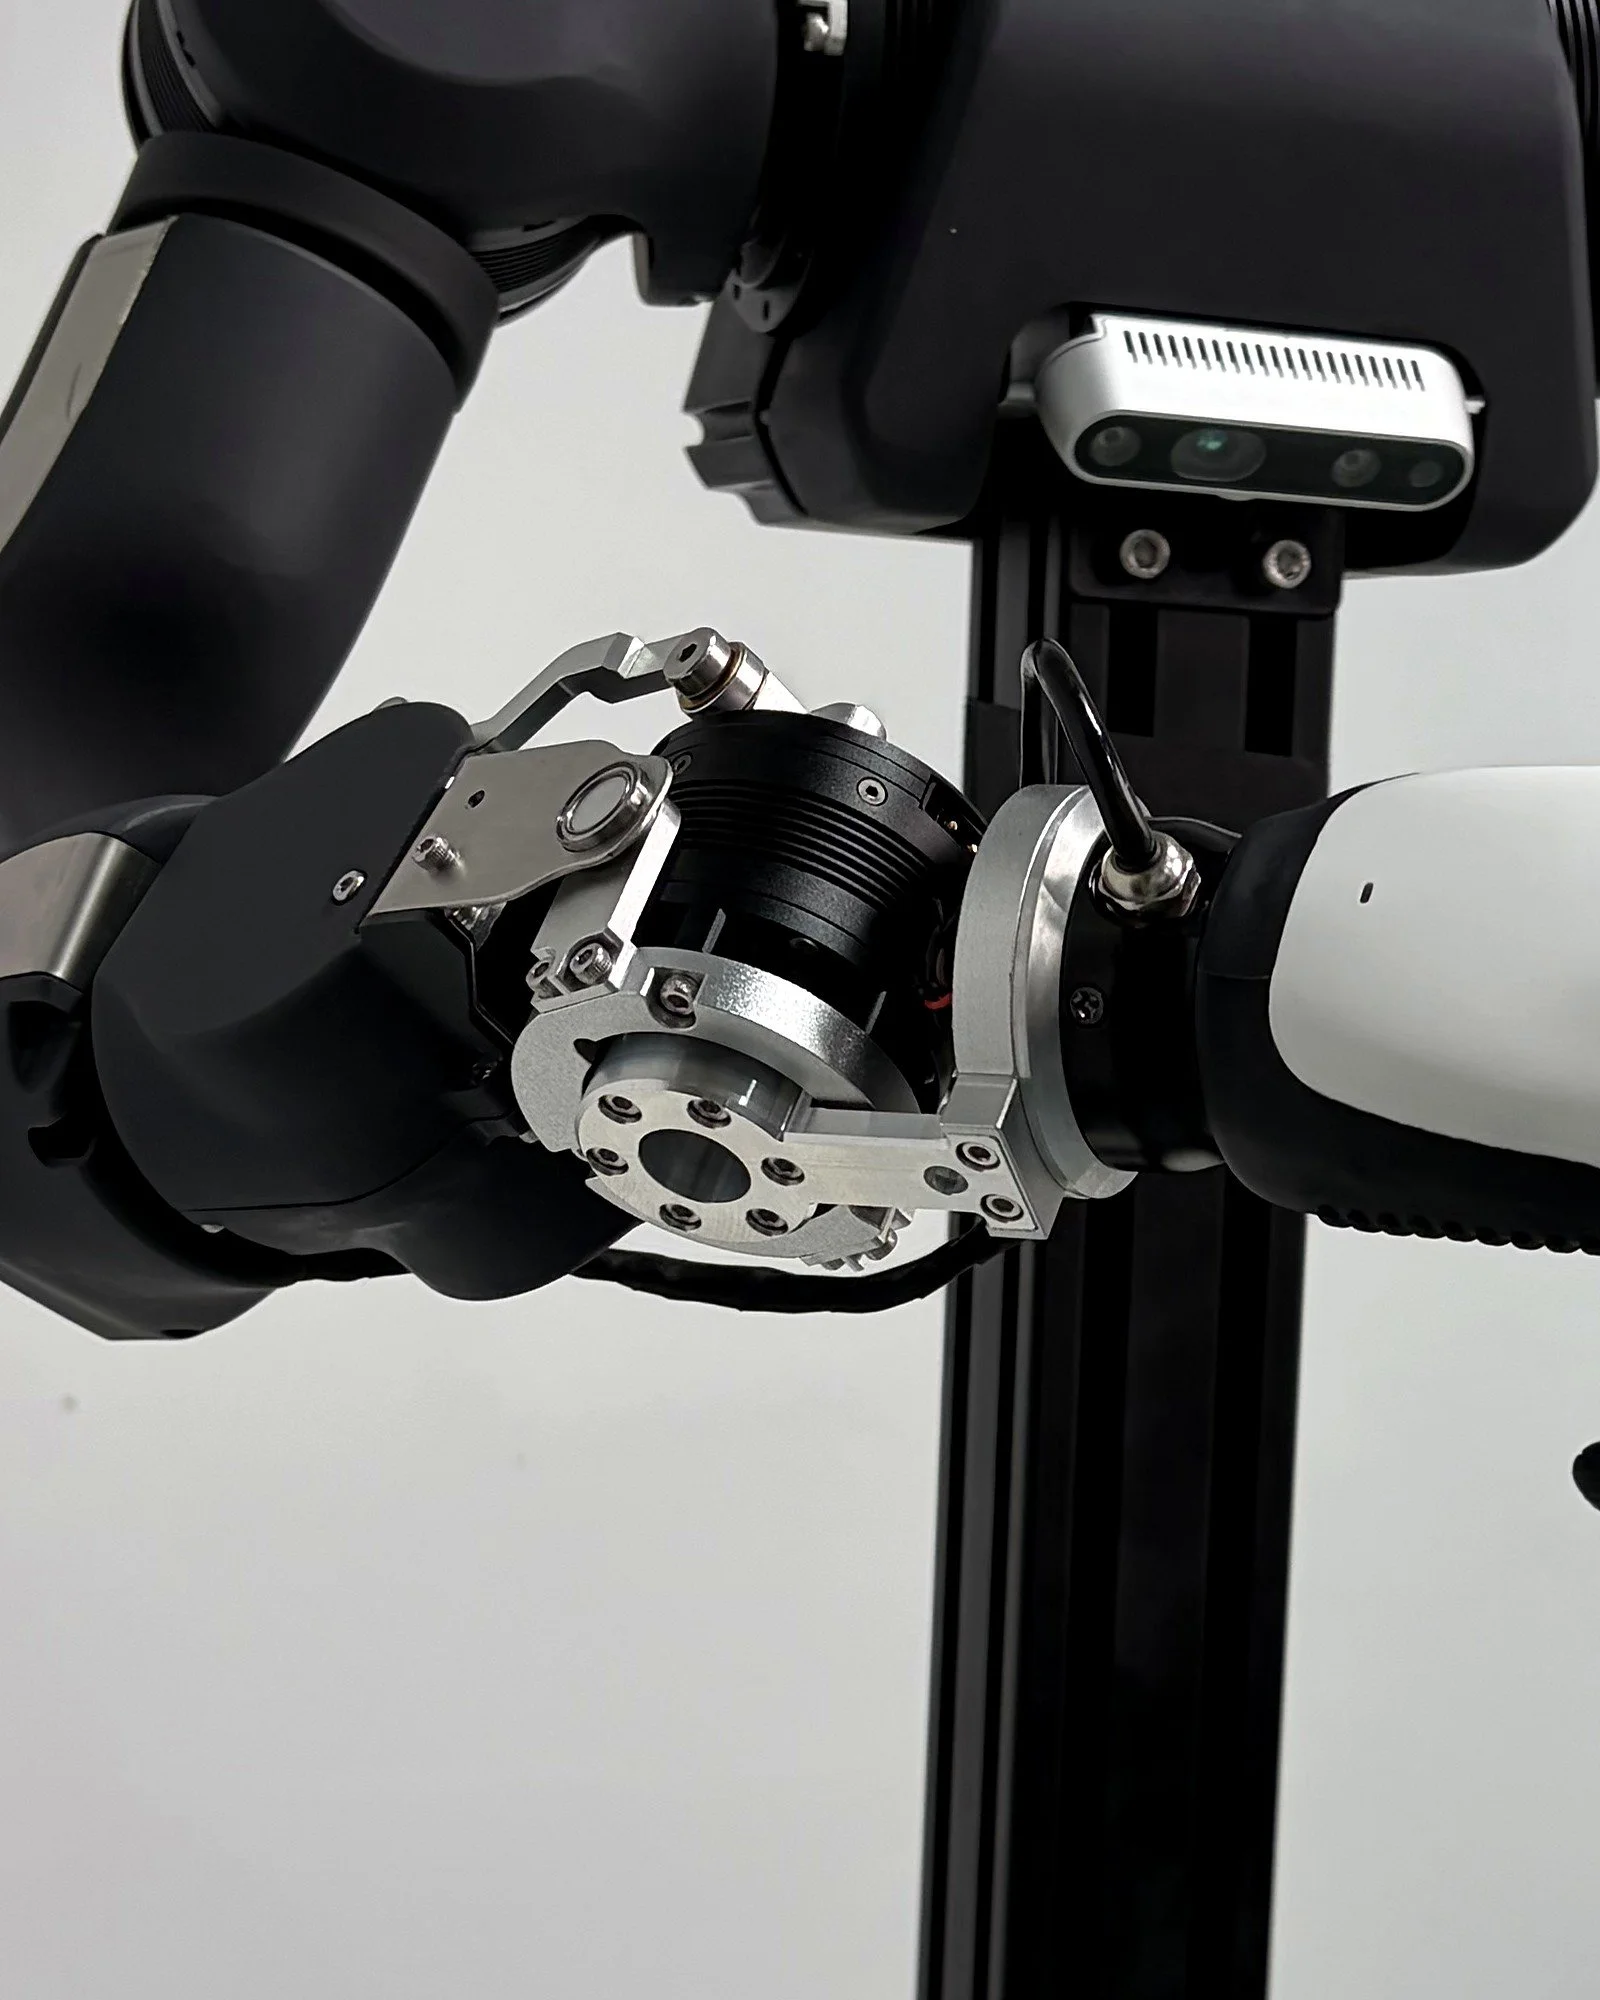
The OYMotion Embodiod Dual-Arm Robot is a dedicated sottwaro-hardwaro system built on the OpenArm open-source master-slave dual-arm robot tor action data acquisitiom Featuring dual 7-DOF humanoid arms With quasi-direct drive motors and master-slavo bidirectional torco toodback, it captures real-time, high-precision full-dimensional motion and torce data trom human upper limbs and hands, enabling accurate motion mapping and standardized data aggregation.
36 DoF — Degree of Freedom
660 mm — Arm Reach
6 kg — Peak payload per arm
7 kg — Weight per arm
PRODUCT VIDEO
See OpenArm in motion
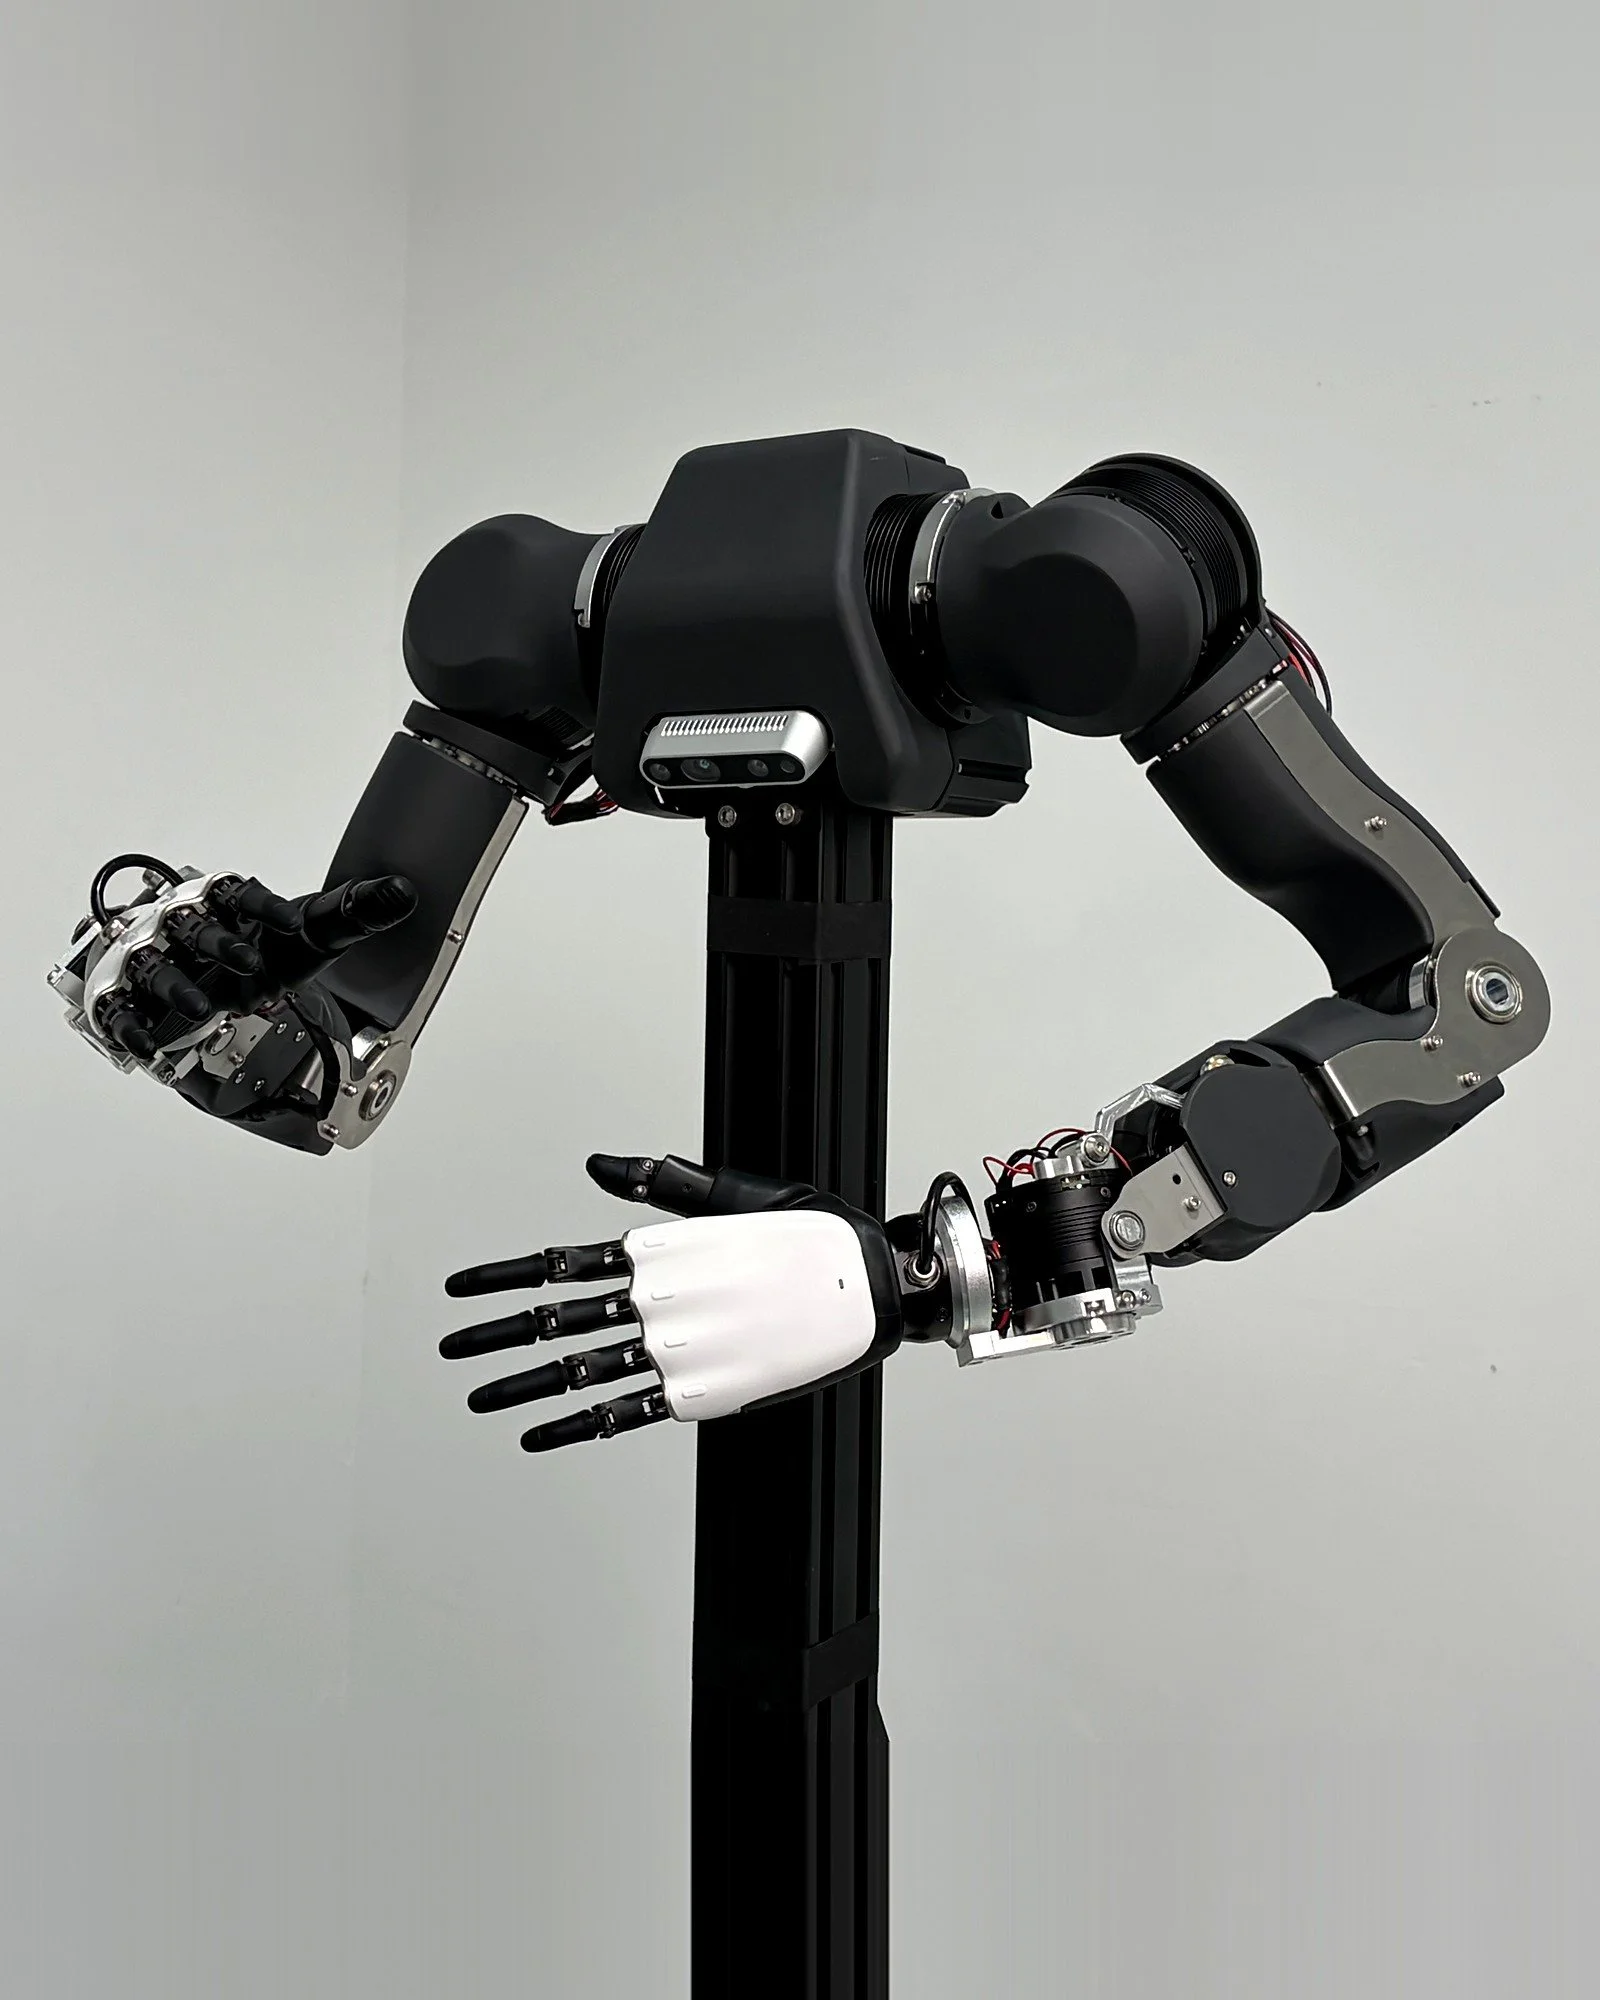
Dual-arm coordination
Two 7-DoF arms support coordinated manipulation and bidirectional master–slave force feedback.
Open development
Open-source hardware and software, with an SDK and documentation for custom development.
Arm and hand integration
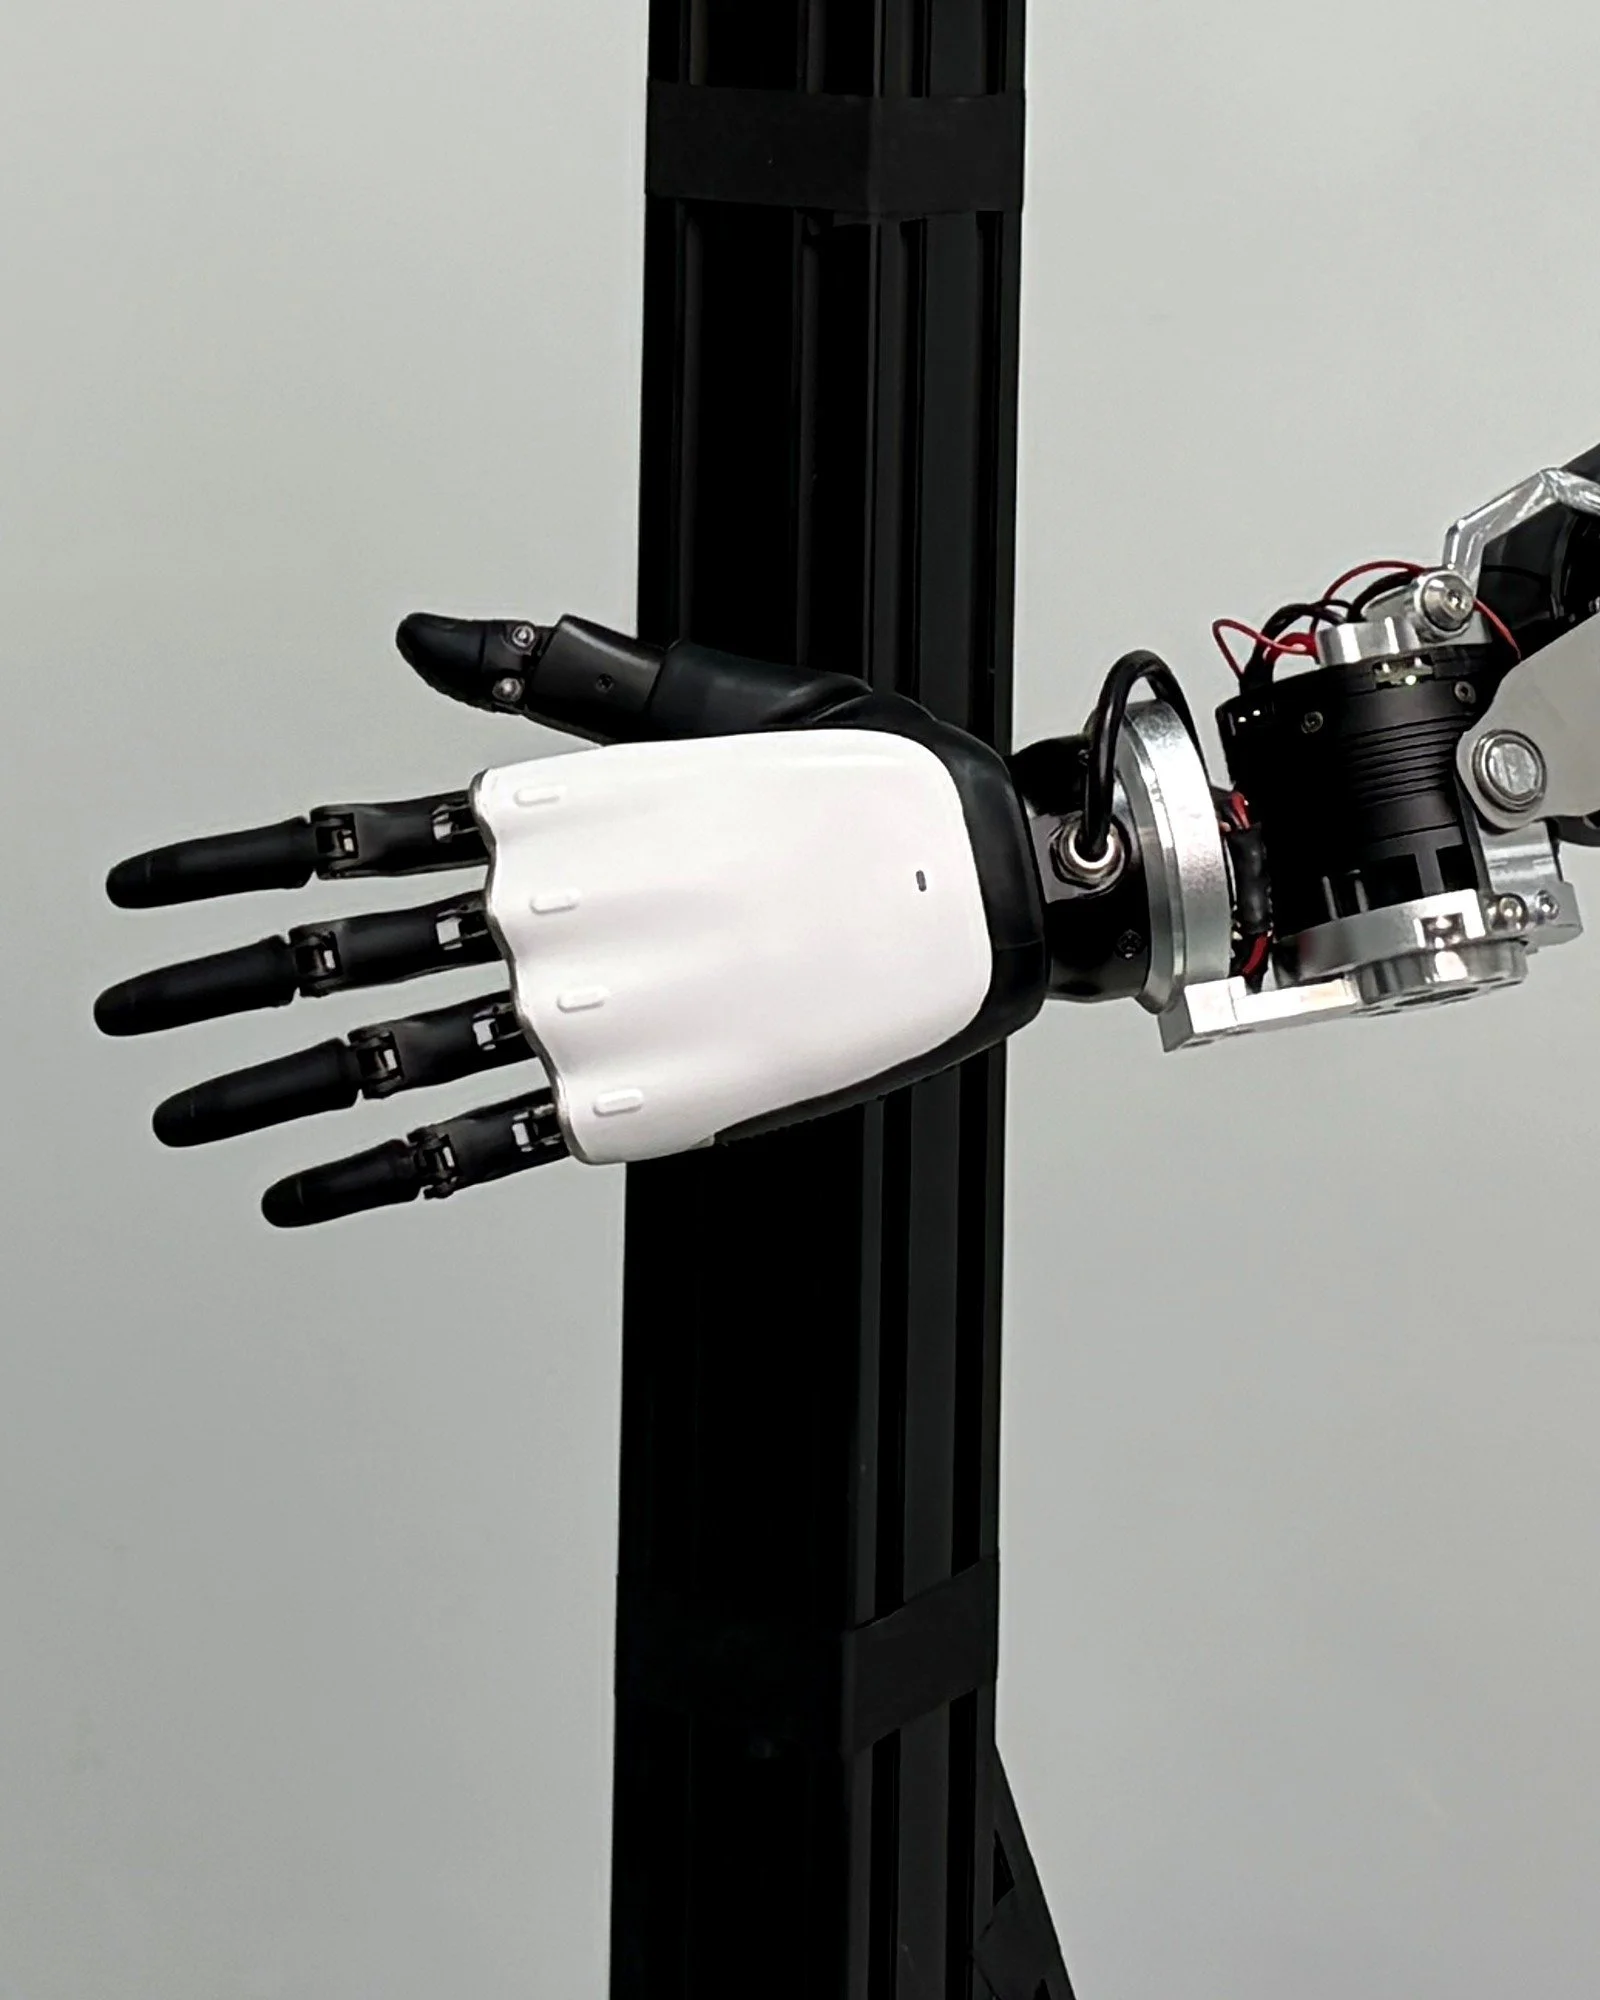
ROHand dexterous hands combine with arm motion and force sensing for manipulation research.
TYPICAL APPLICATIONS
Motion data collection — Capture demonstrations for robot-learning workflows.
Teleoperation research — Explore human-guided control and force-feedback interaction.
Dexterous manipulation — Develop and evaluate coordinated arm-and-hand movements.
TECHNICAL DETAILS
Specifications & compatibility
Key specifications from the manufacturer. Final specifications depend on the selected configuration.
OpenArm dual-arm system
Arm configuration — 2 × 7 DoF
Reach per arm — 660 mm
Weight per arm — 7 kg
Payload per arm — 4.1 kg nominal / 6 kg peak
Operating area — 60 × 40 cm
Force feedback — Bidirectional, master–slave
ROHand dexterous hands
Joints per hand — 11 motion joints / 6 active
Full-range movement — 0.7 s at maximum speed
Fingertip active force¹ — ≥ 0.5 kgf
Thumb-tip active force — ≥ 1.0 kgf
Four-finger passive load² — 30 kg
Single-finger passive load² — 10 kg
Software ecosystem
ROS · Ubuntu · Windows · Unreal Engine · Unity
CONFIGURATION & ENQUIRIES
Tell us about your application
We help clarify the product configuration and coordinate technical questions with the manufacturer.
01 Product selection
Discuss reach, payload, hand options and your research workflow.
02 Technical coordination
Review interfaces, software needs and integration requirements.
03 Project follow-up
Discuss delivery, documentation and support arrangements.