
Products / Mobile Bases / SLAMTEC Poseidon
SLAMTEC
Poseidon
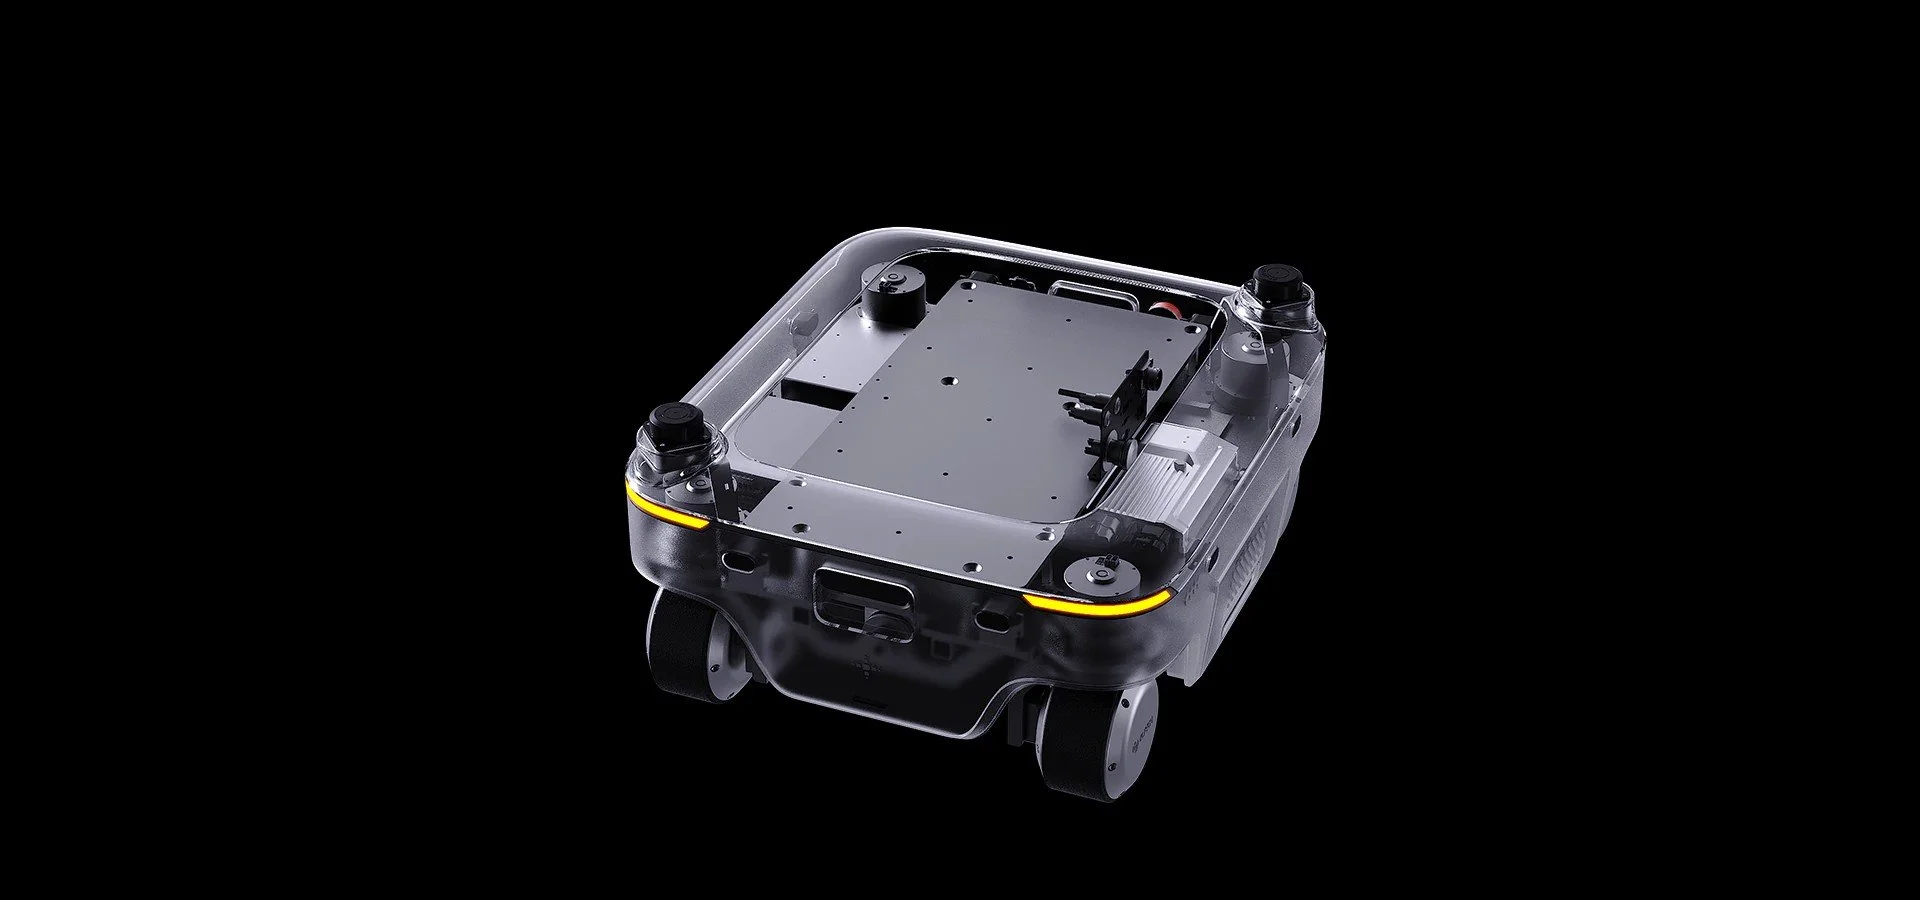
Omnidirectional Mobile Robot Base
A four-wheel independent steering base for embodied AI and humanoid robots, with front and rear LiDAR, depth cameras and an open SDK with ROS / ROS 2 support.
Description:
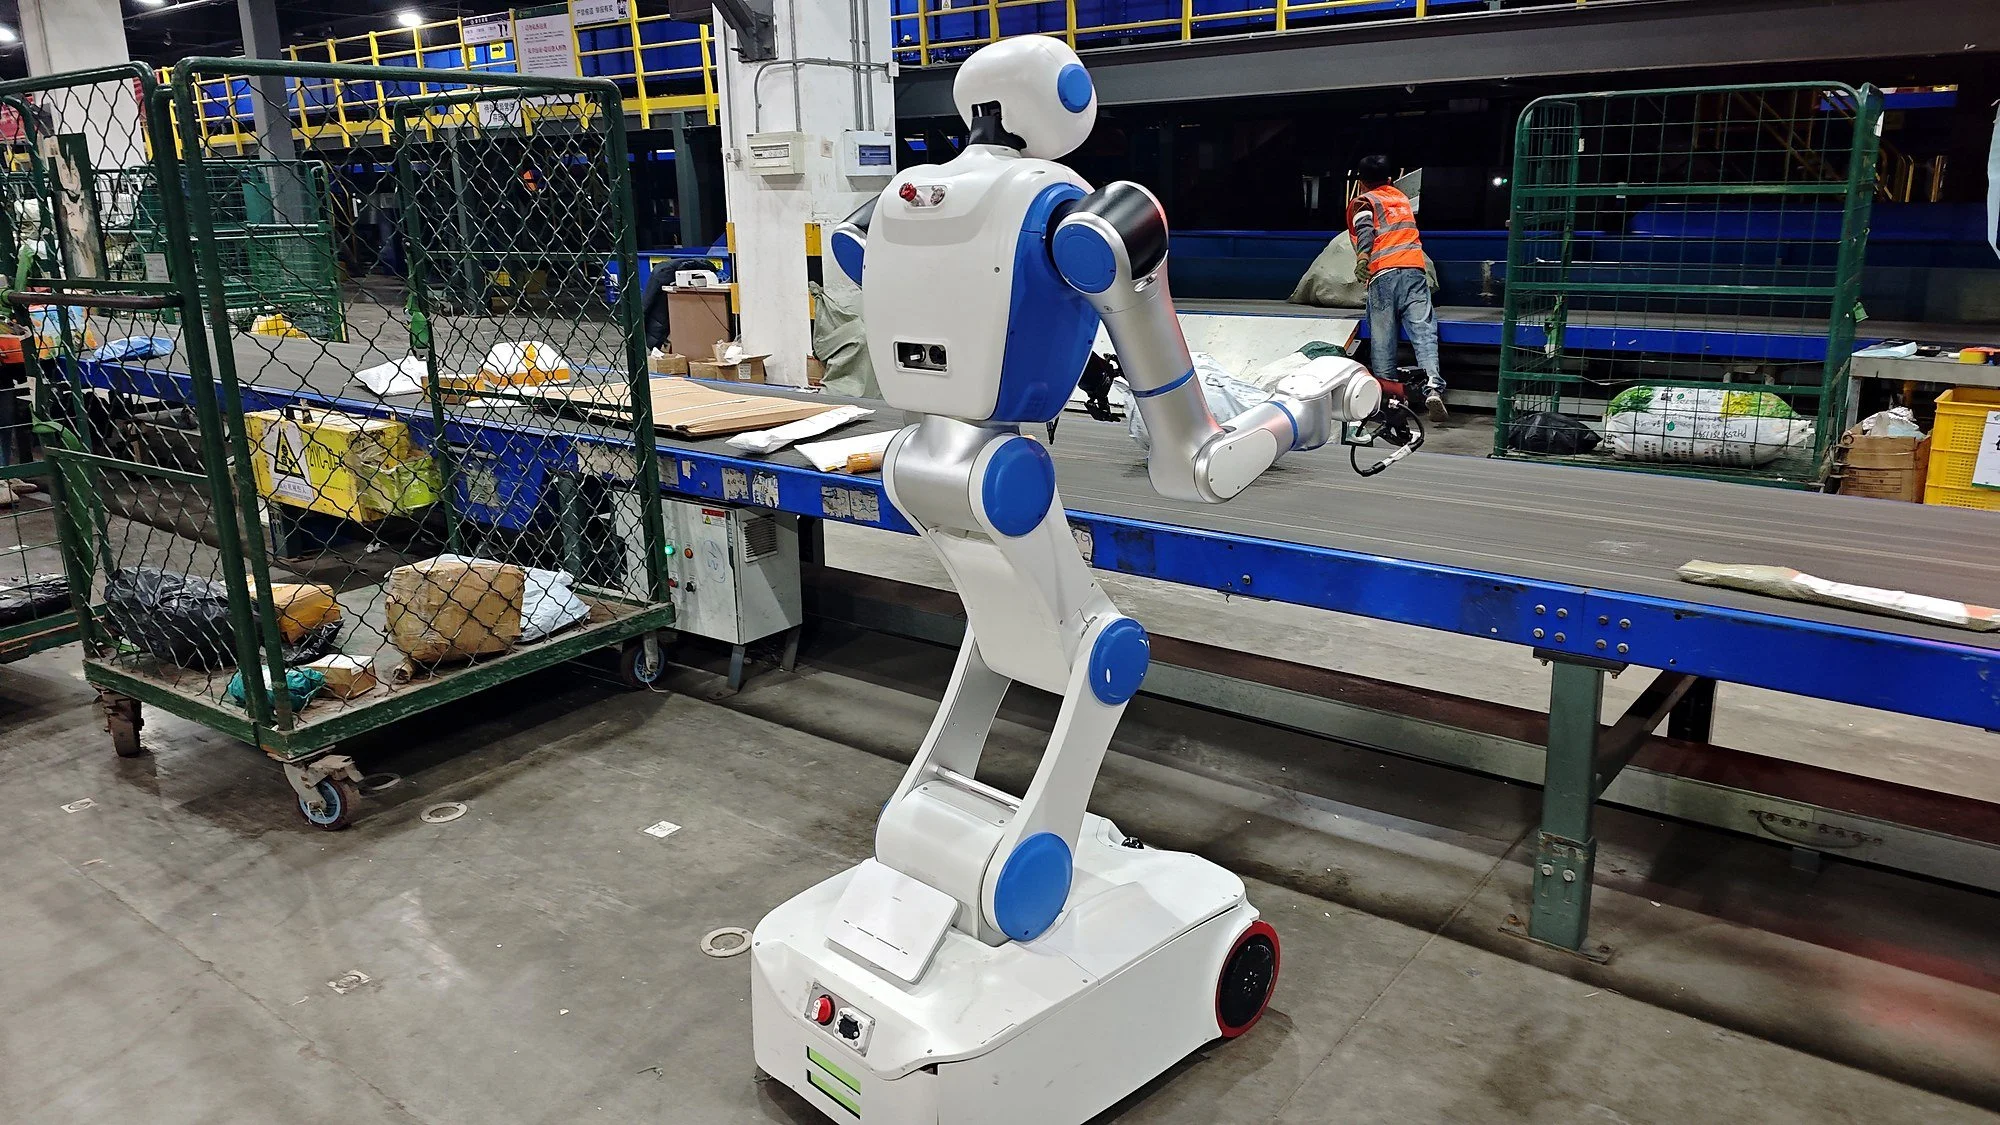
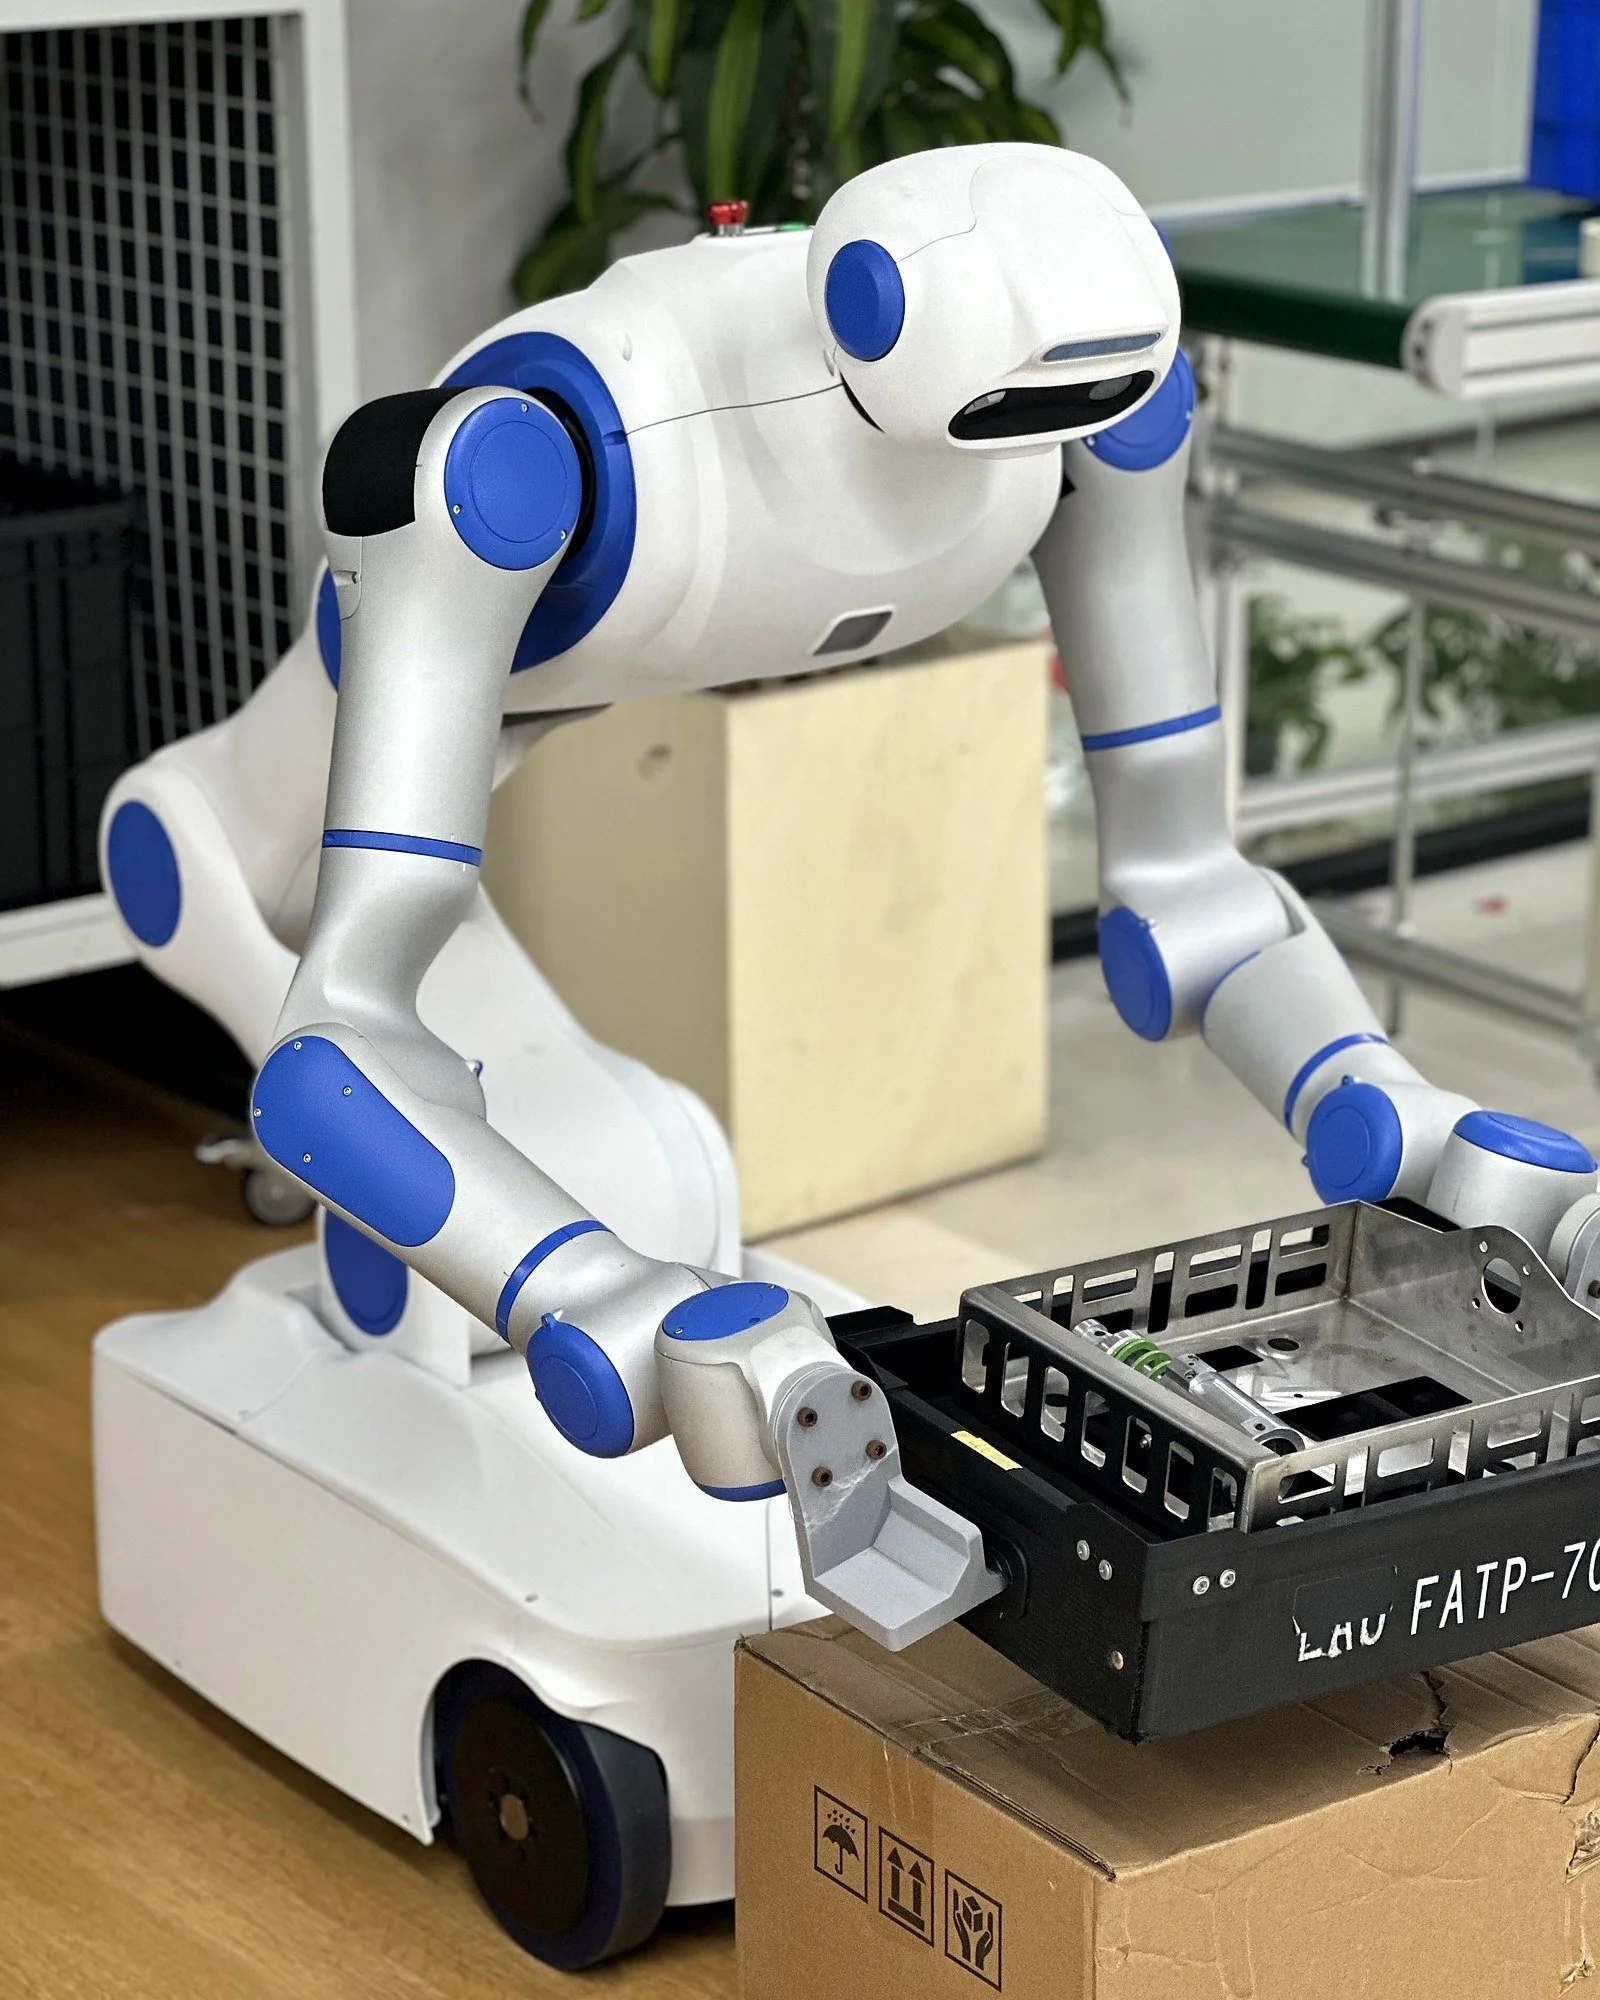
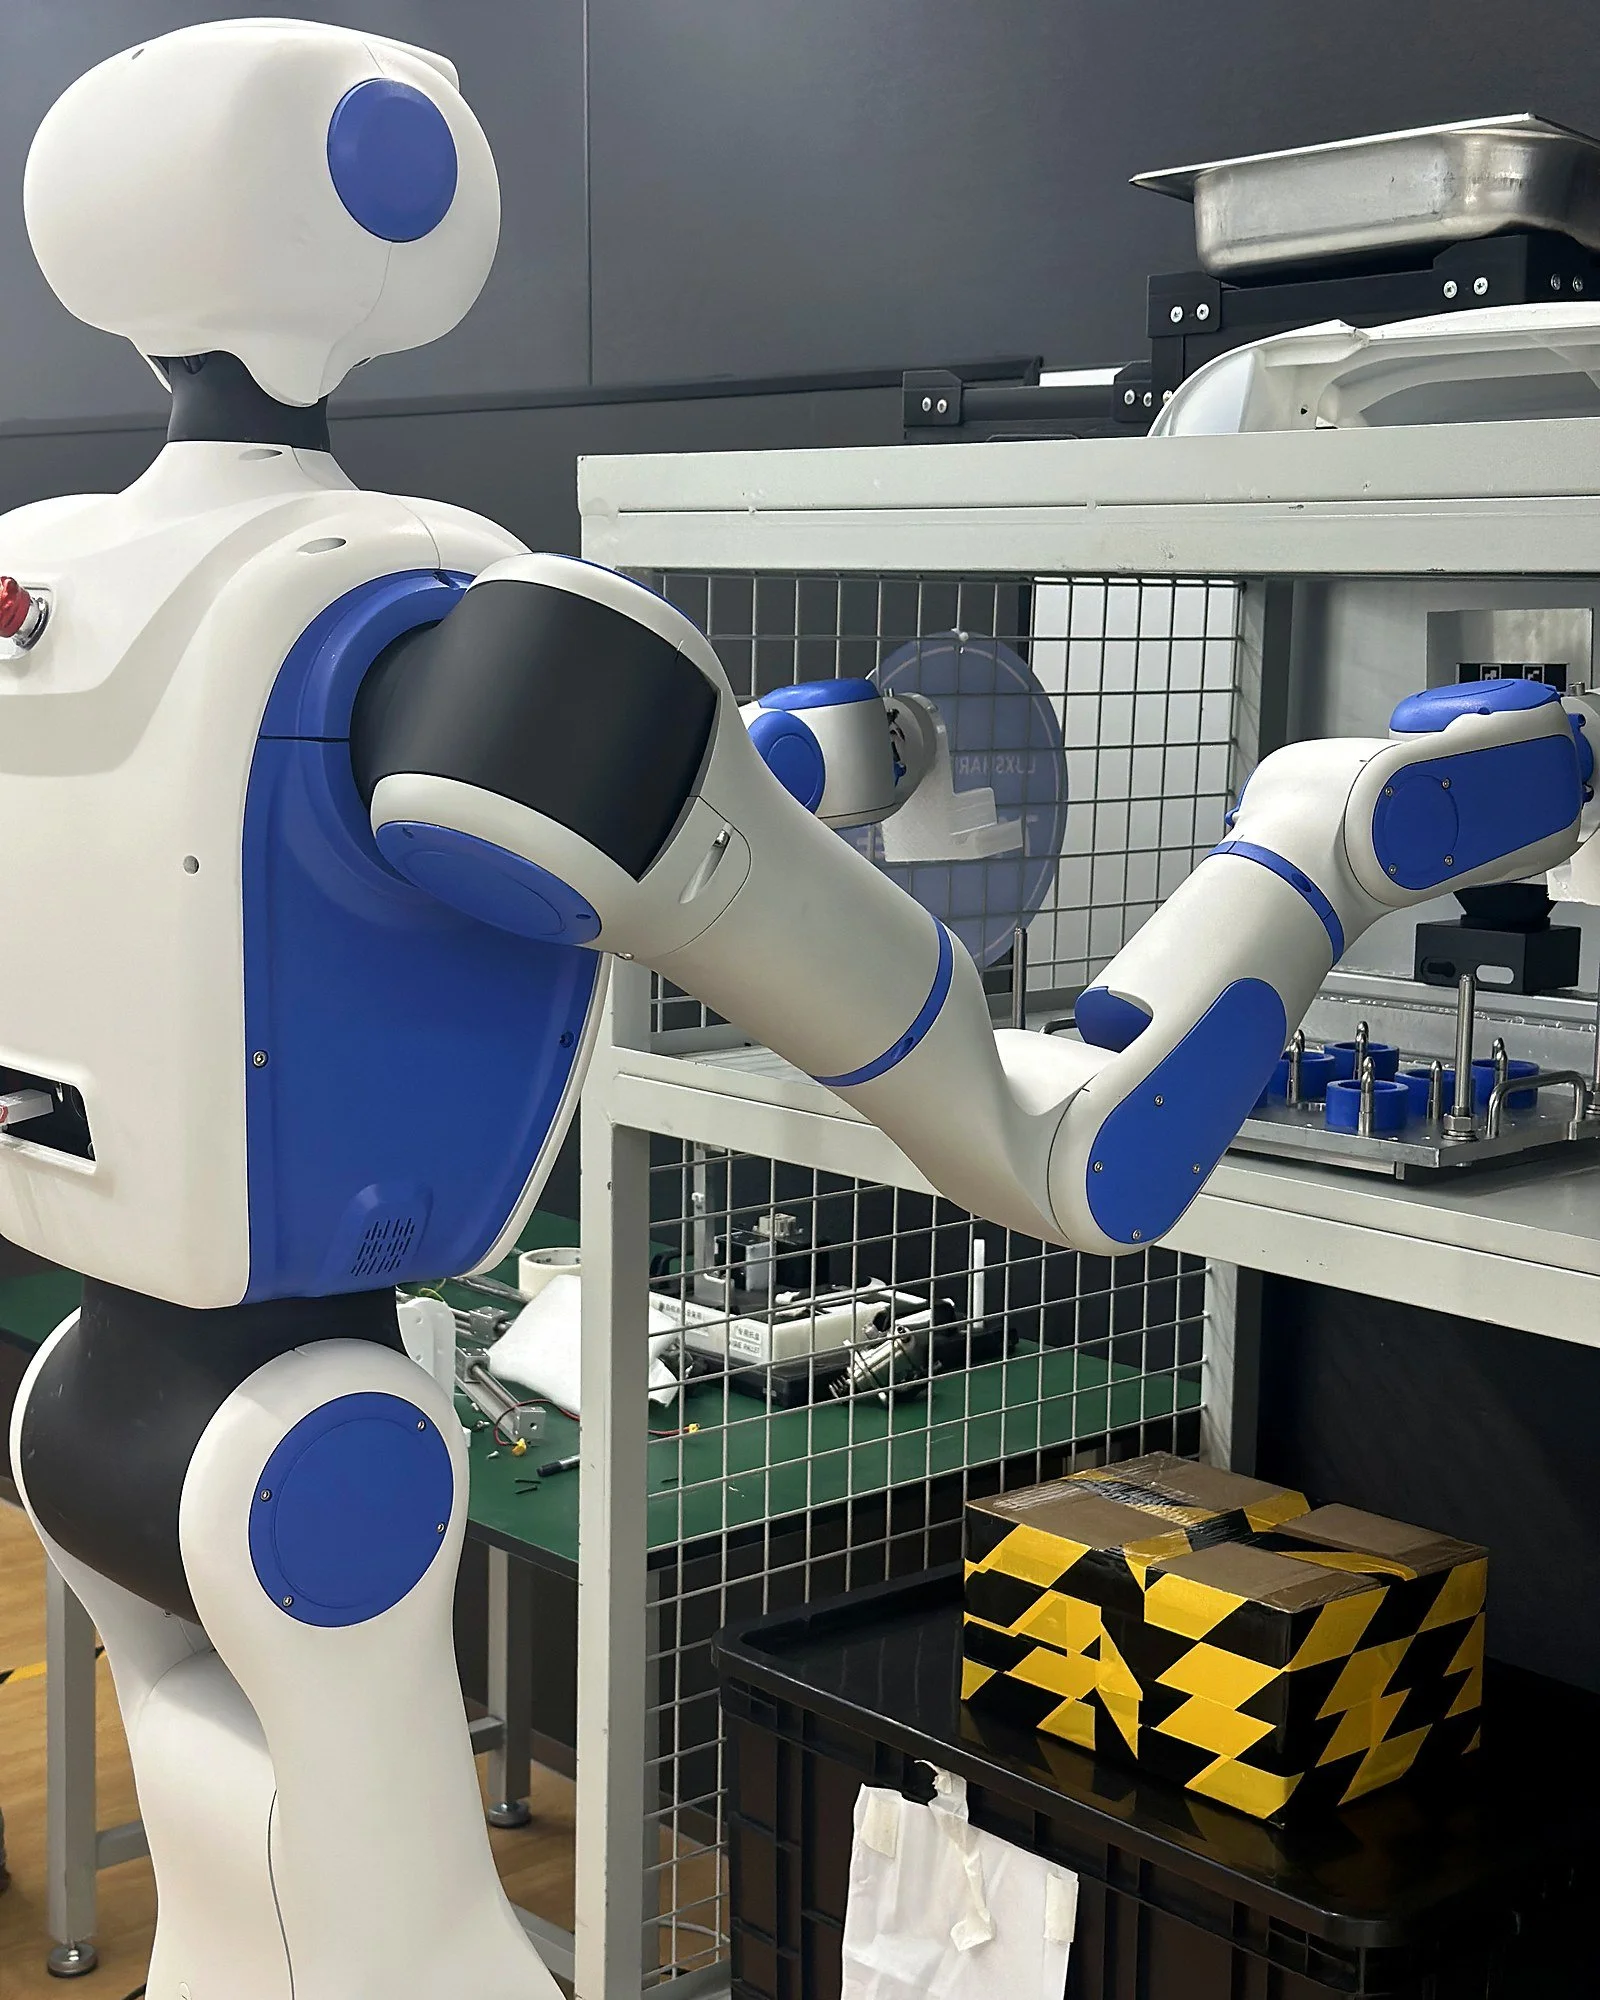
SLAMTEC Poseidon is an omnidirectional mobile robot base with four-wheel independent steering for lateral, diagonal and in-place motion. It carries a rated payload of 150 kg (max. 200 kg), provides a 48 V / 30 A power output for robot arms and upper bodies, and combines front and rear LiDAR, depth cameras and ultrasonic sensors for 360° obstacle detection. An open SDK with ROS / ROS 2, C++ and Python support helps integrate custom upper structures for embodied AI, humanoid and industrial applications.
150 kg — Rated payload
1.5 m/s — Max. speed
8 h — Operating time
±20 mm — Stopping accuracy
KEY FEATURES
Poseidon at a glance
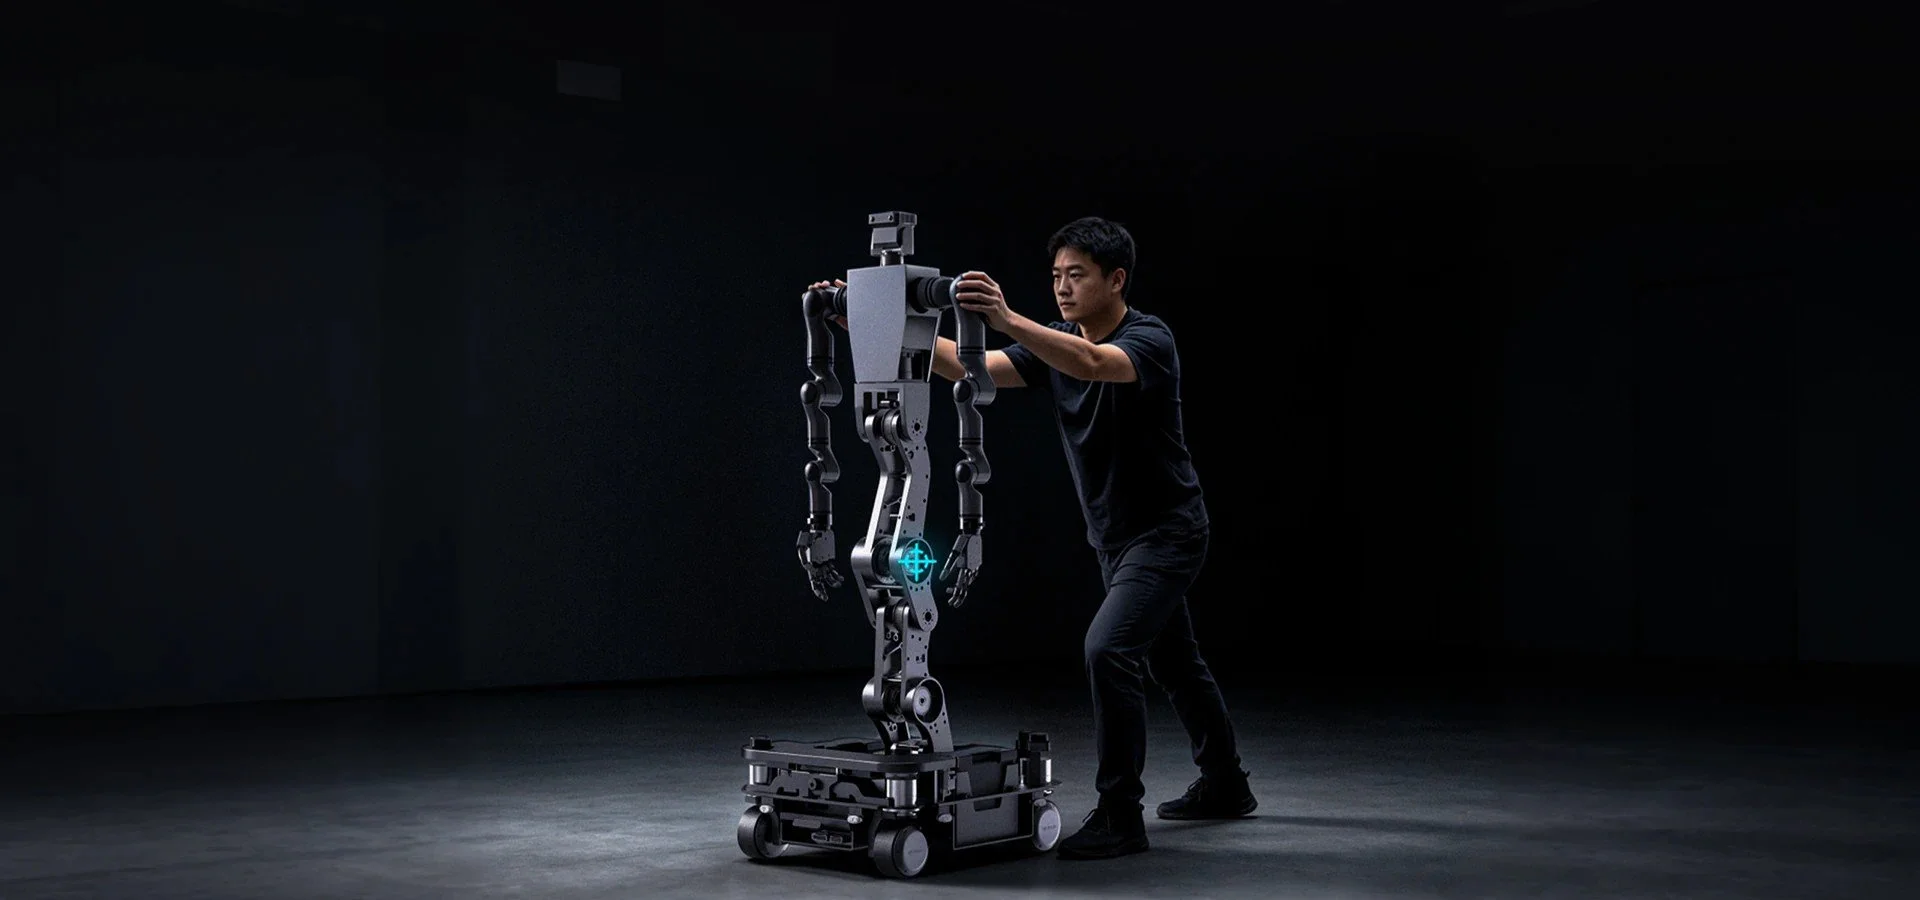
Four-wheel independent steering
Lateral movement, zero-radius rotation, diagonal driving and parking mode for narrow spaces.
360° obstacle detection
Front and rear LiDAR, dual depth cameras and eight ultrasonic sensors. 3D LiDAR optional.
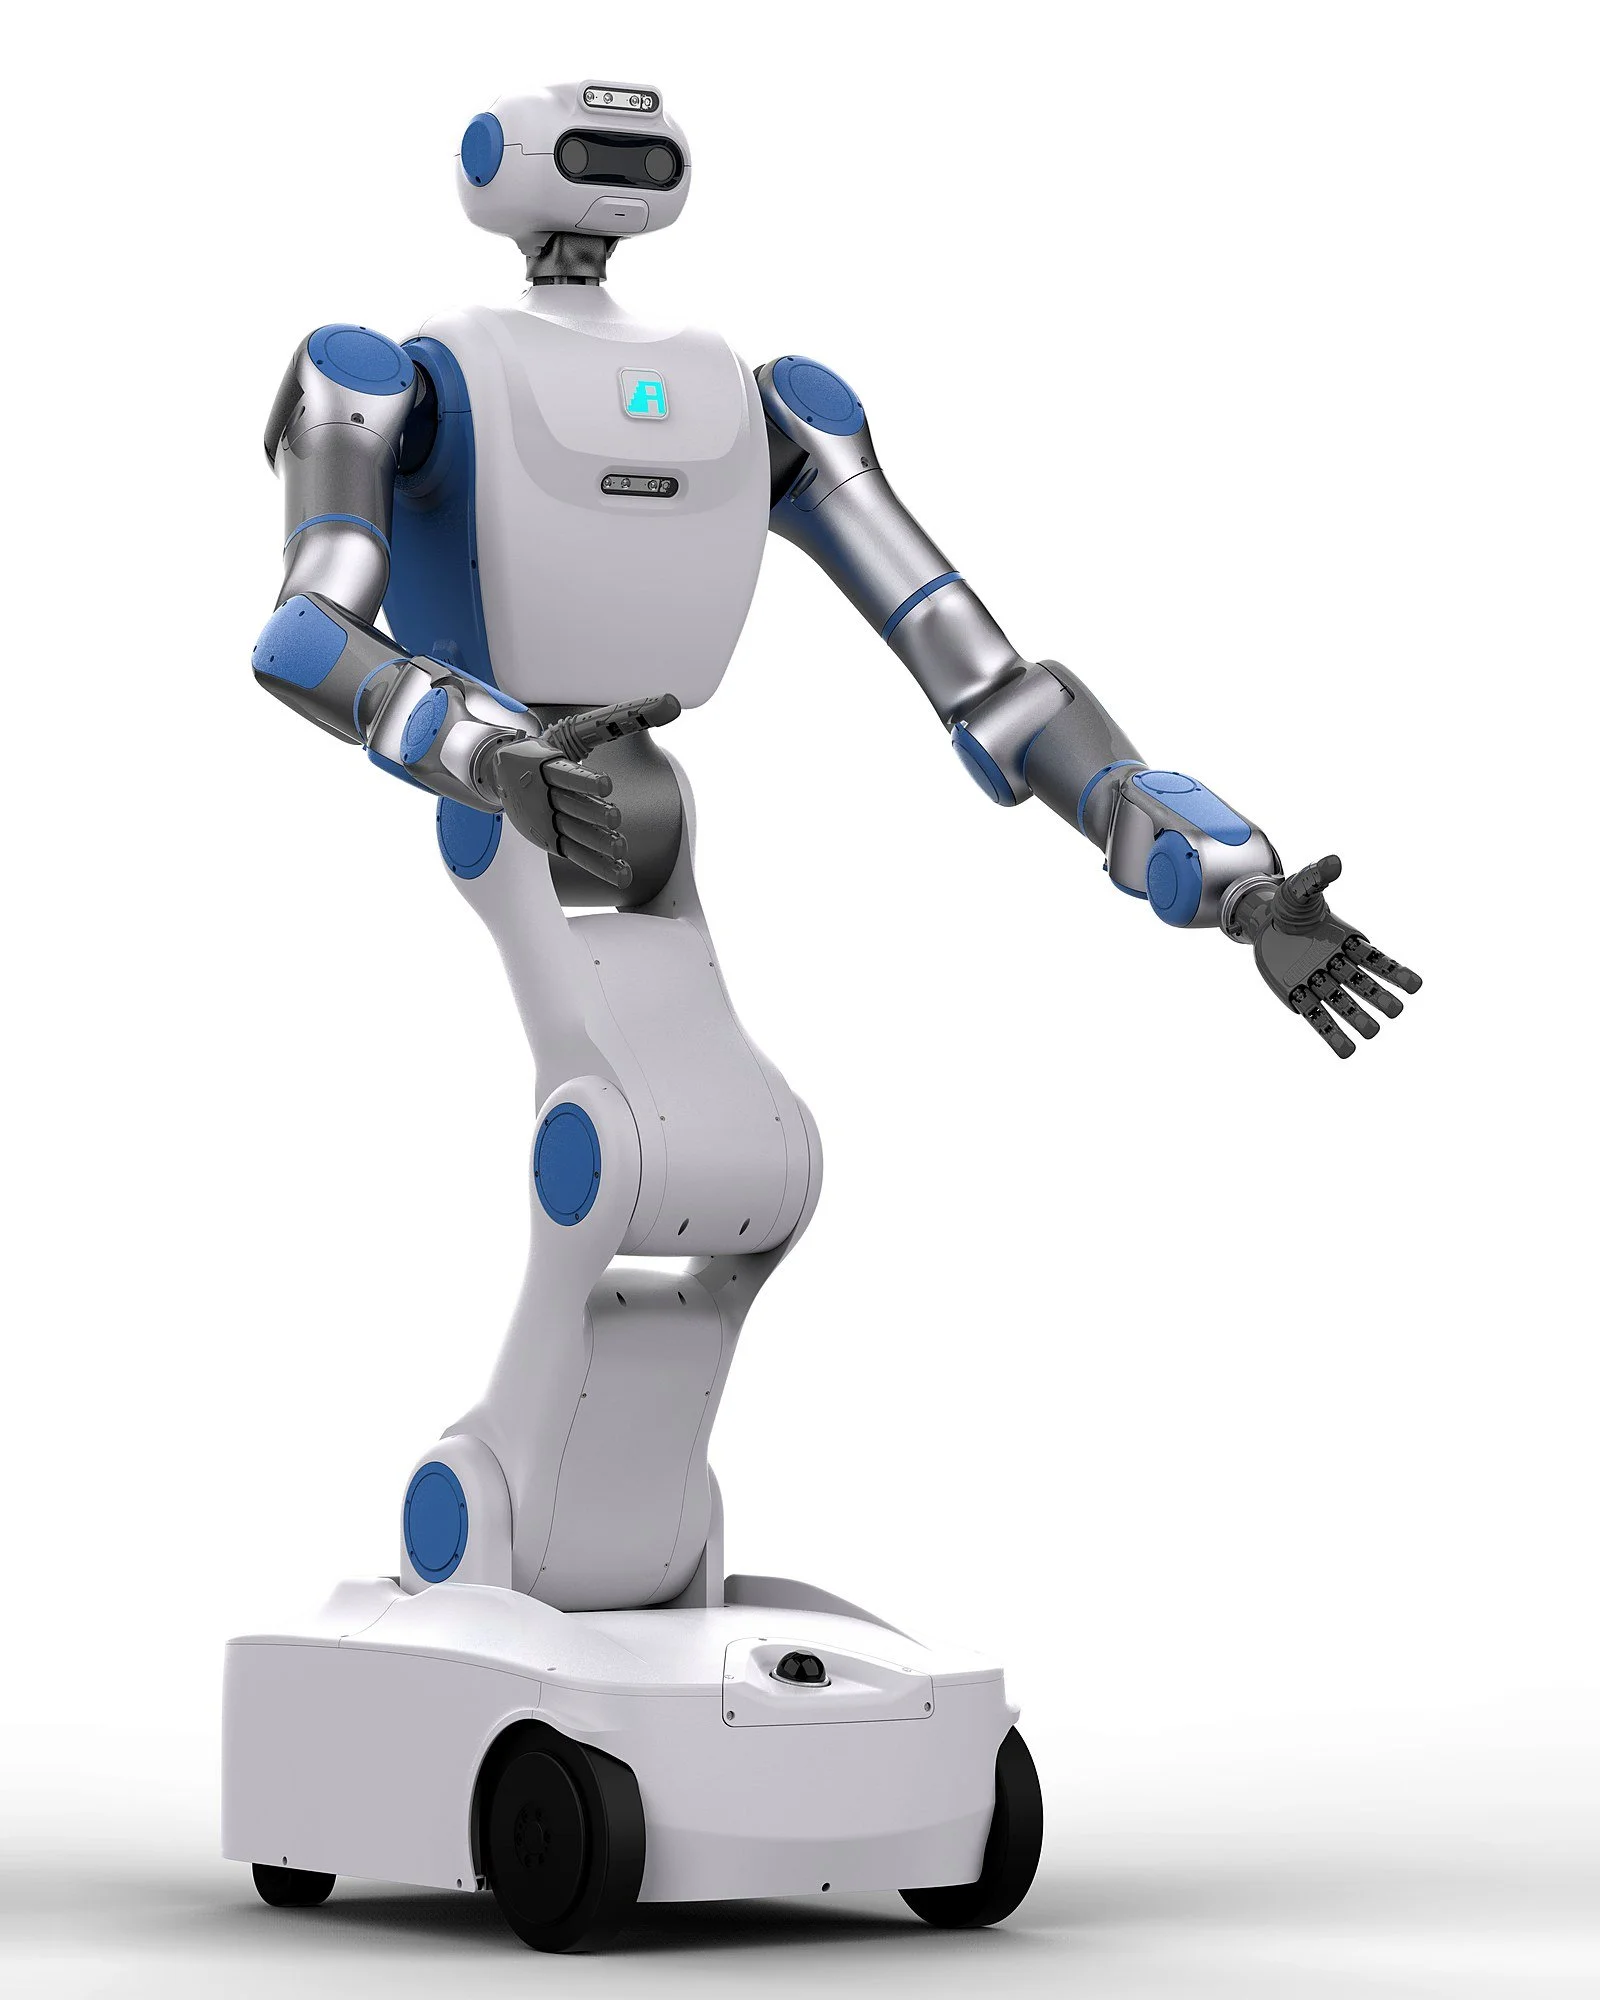
Built for tall upper bodies
Stable motion at a total robot height of 1.8 m, with column, folding and lifting upper-structure options.
TYPICAL APPLICATIONS
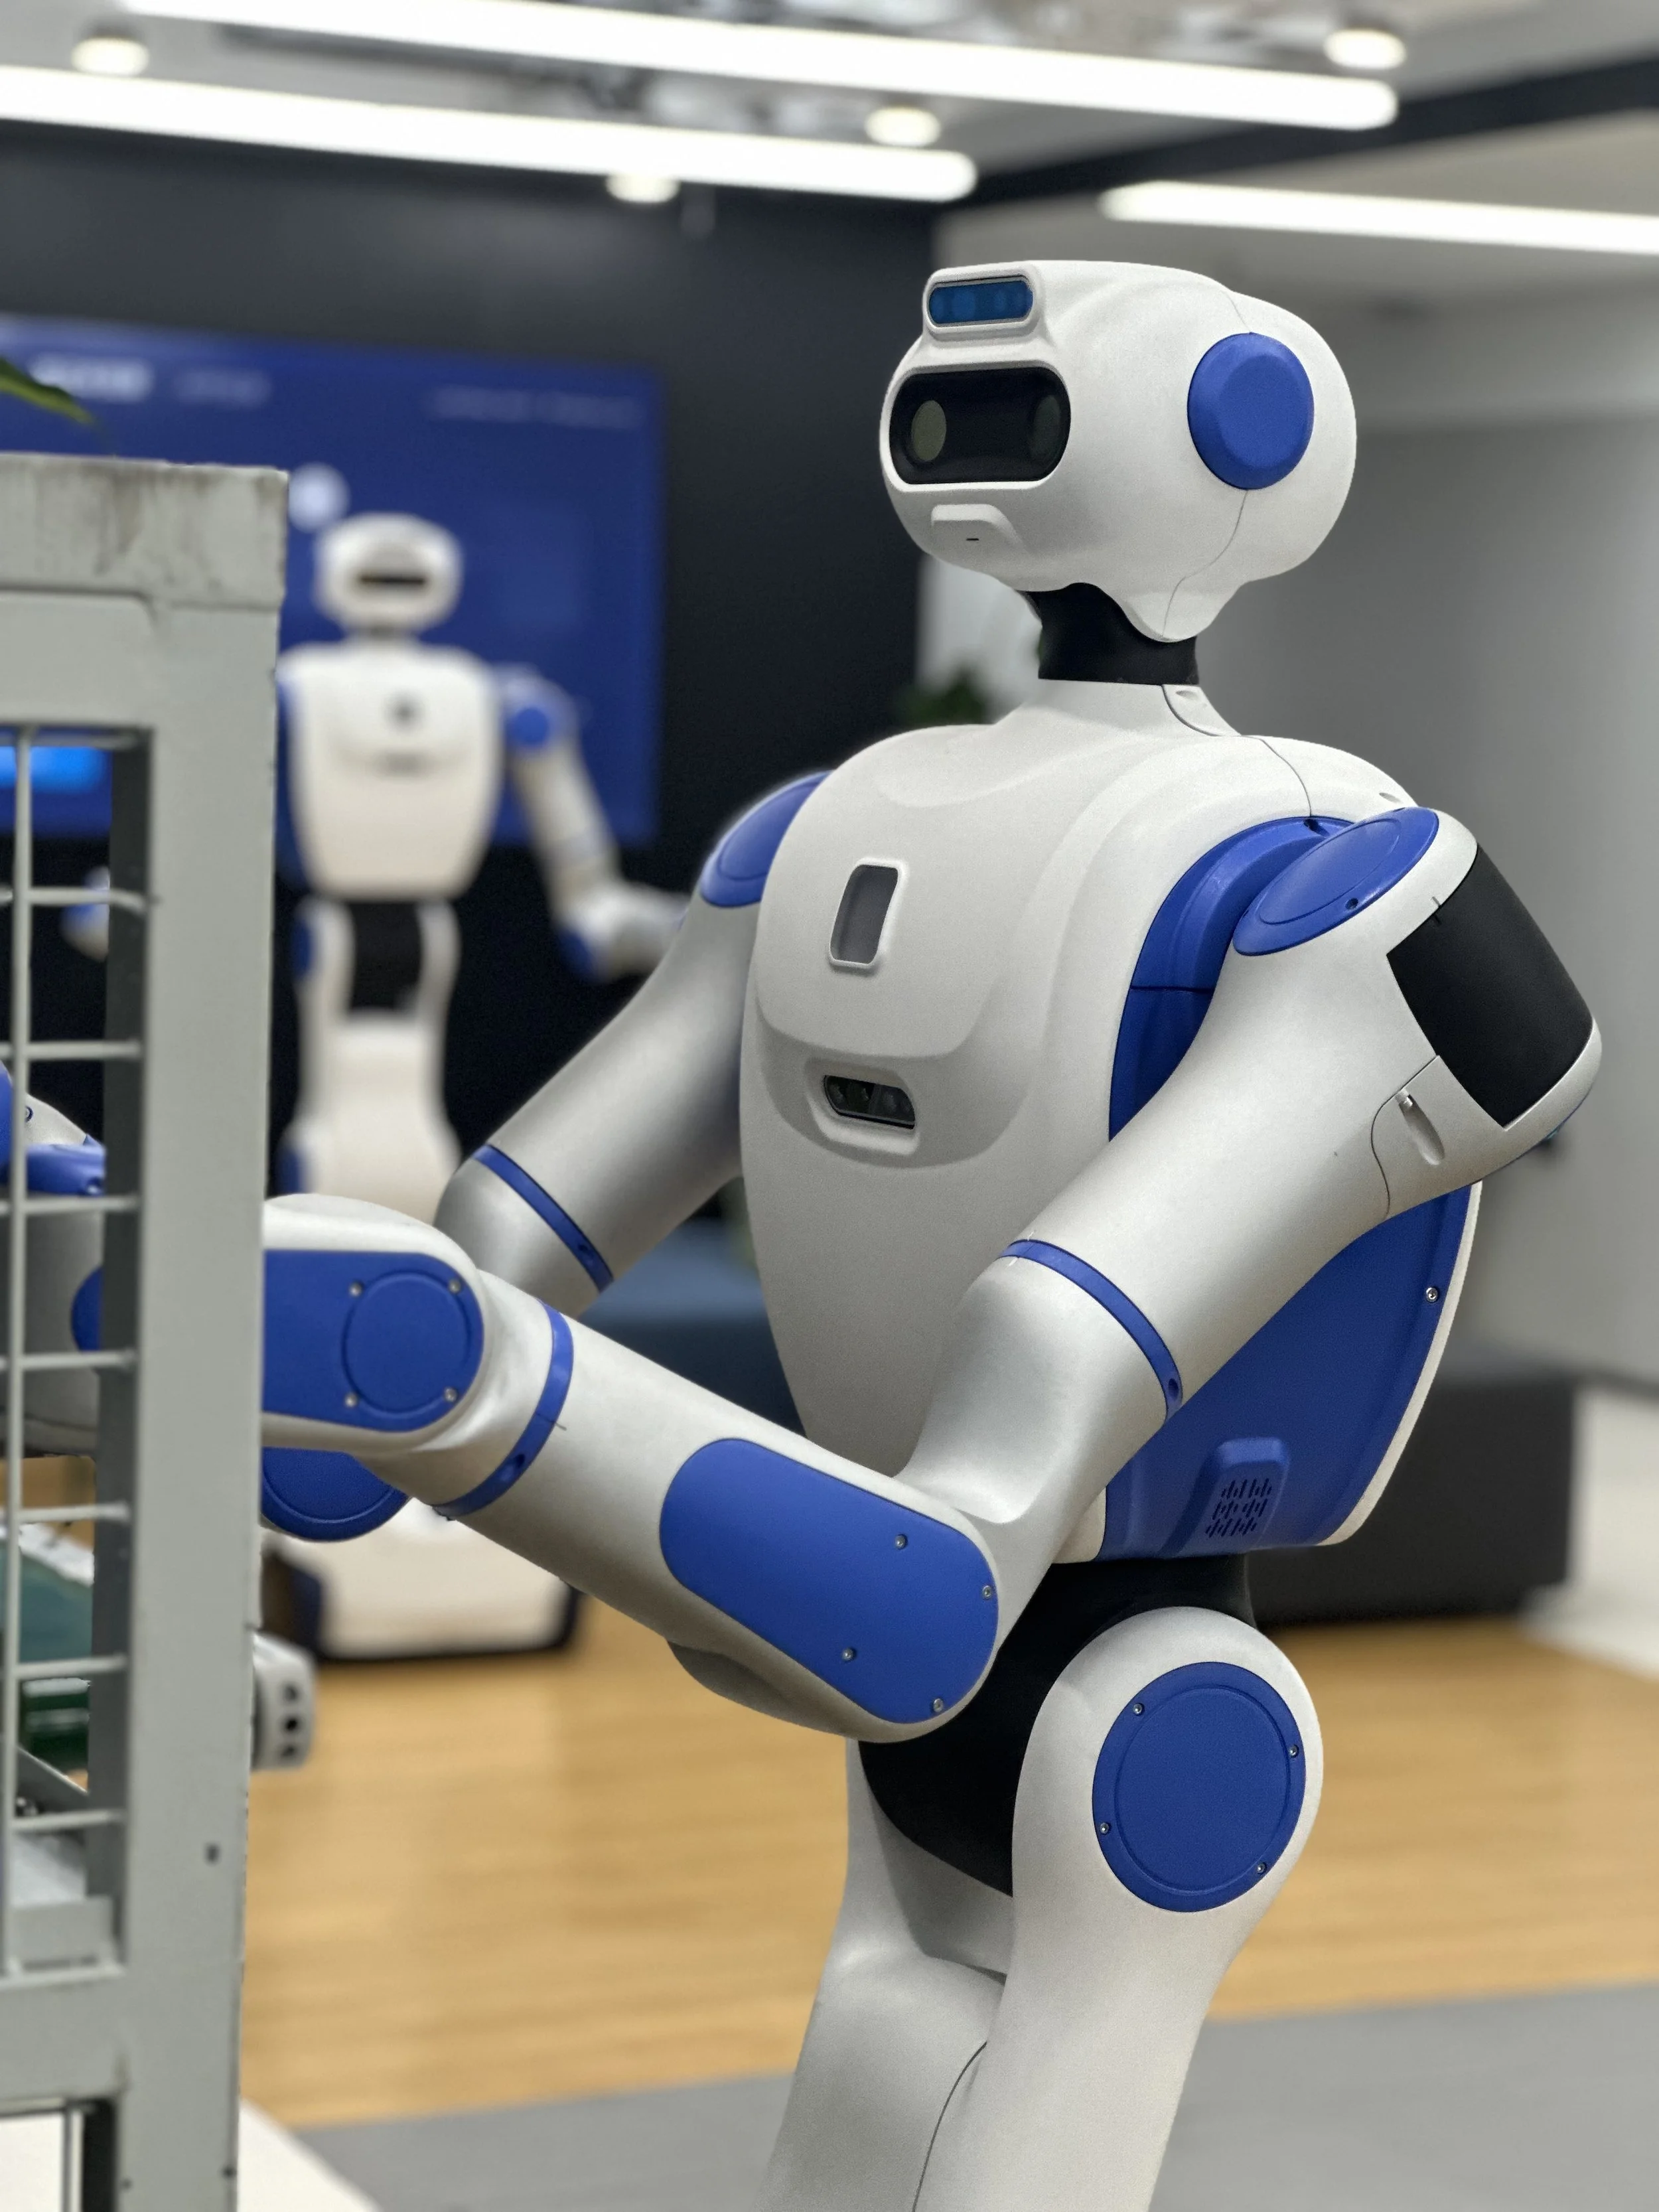
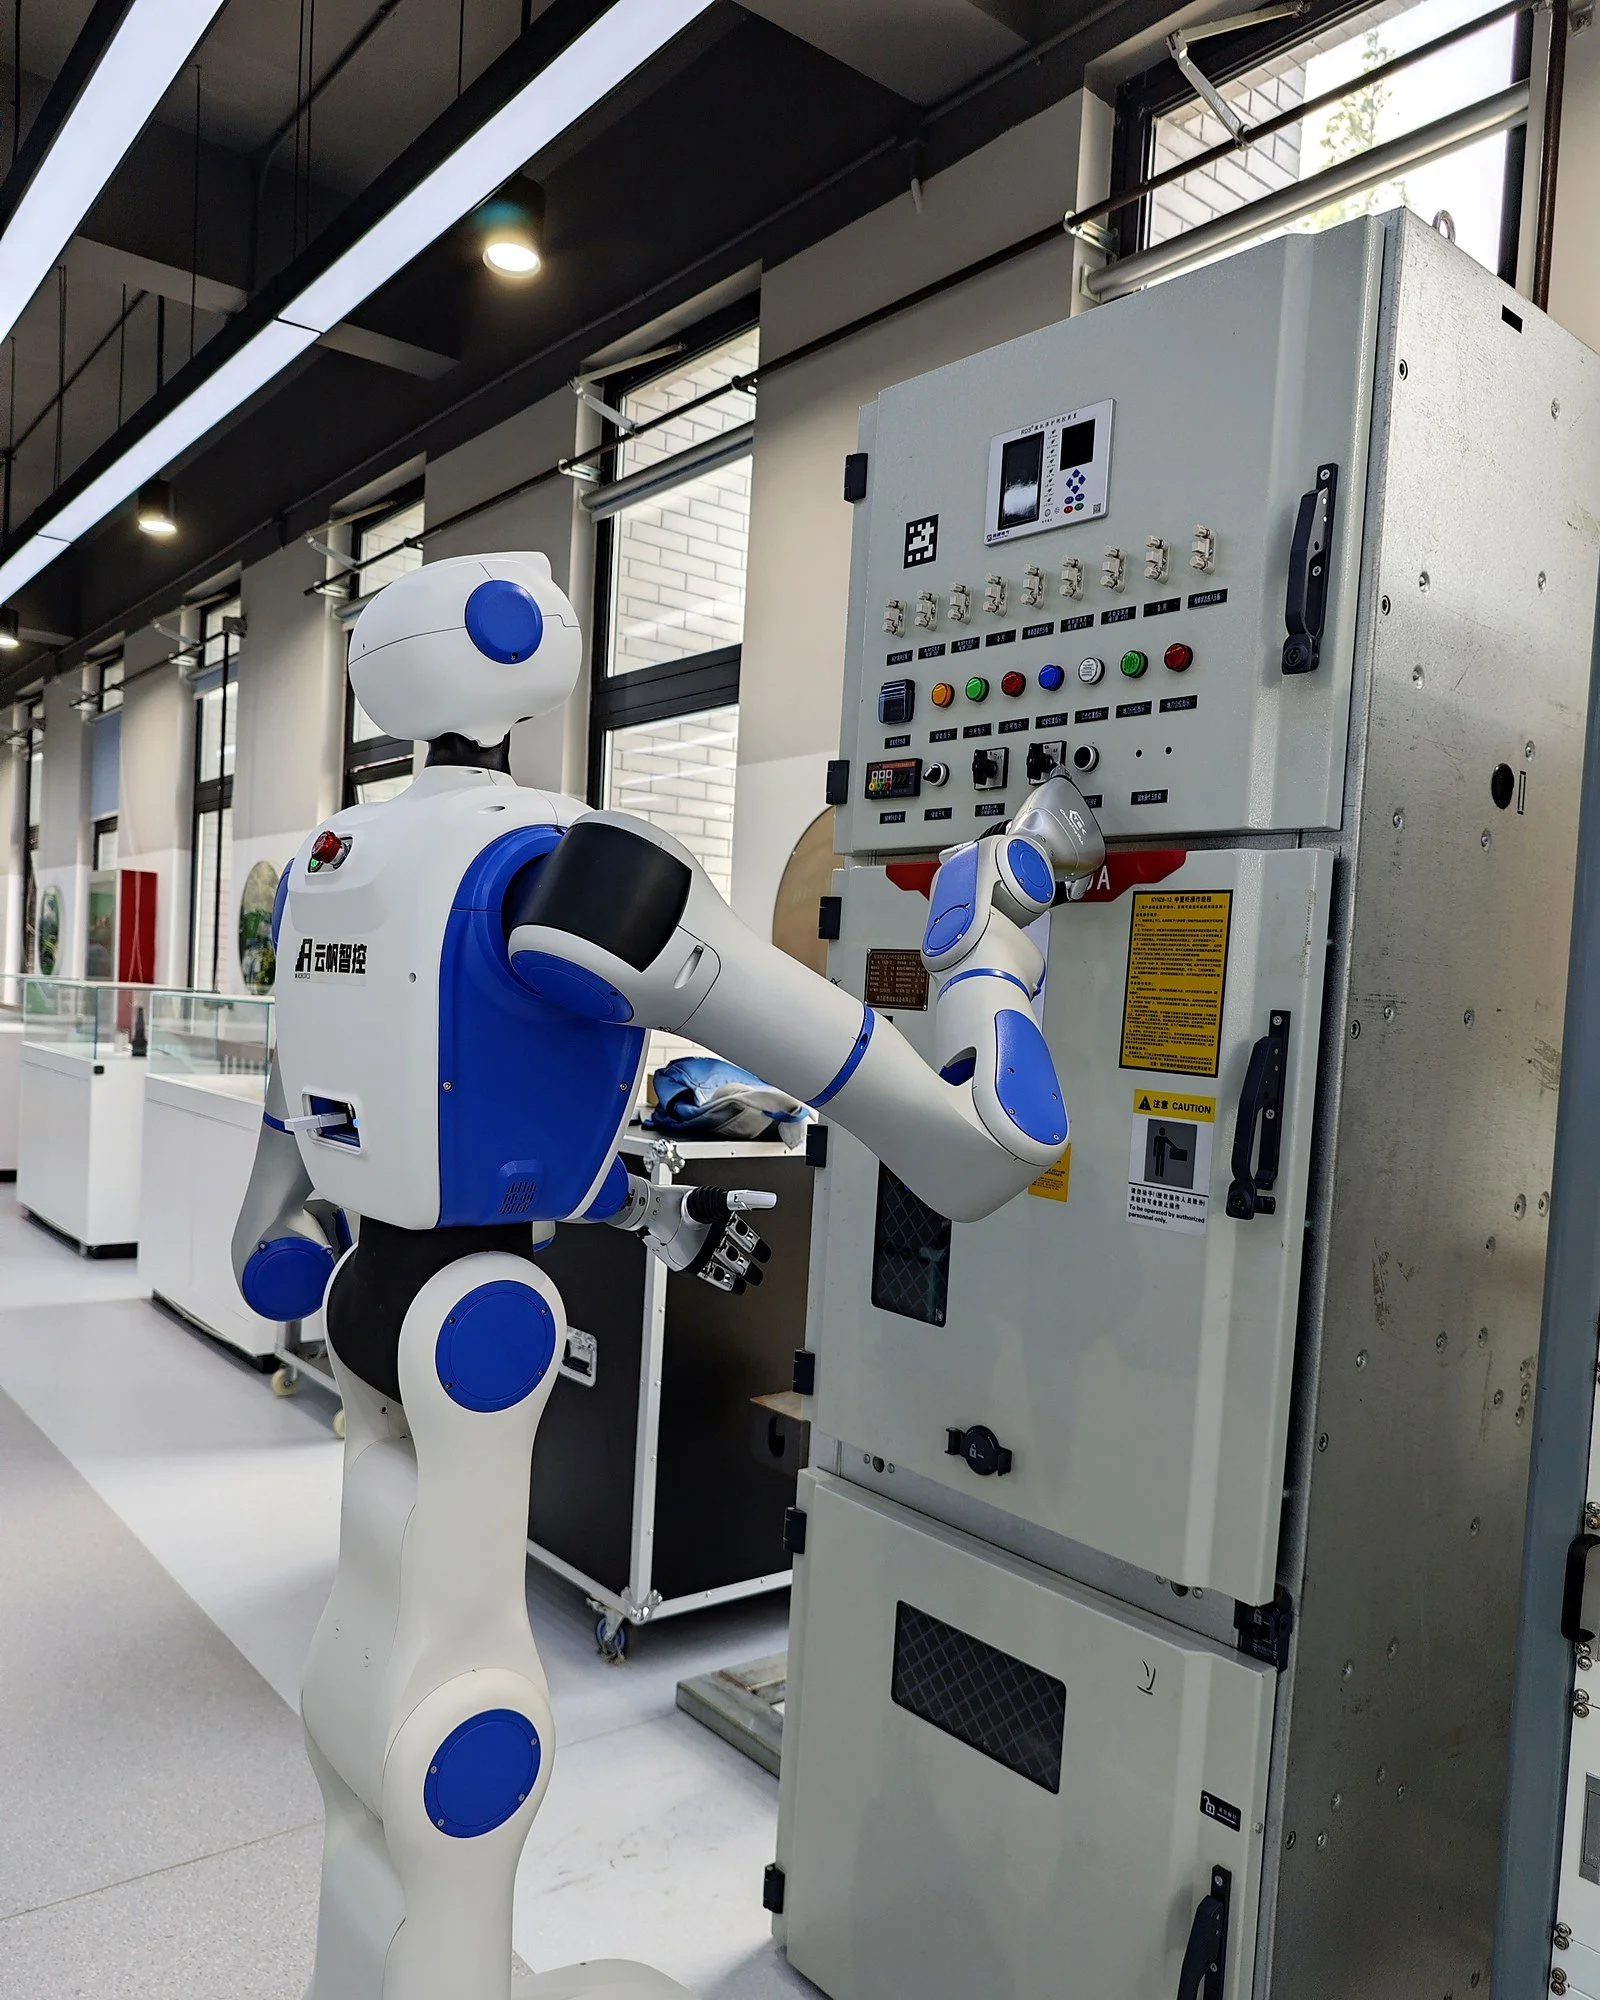
Embodied AI & humanoids — Mobile base for dual-arm and humanoid upper bodies.
Industrial operations — Material transport and mobile manipulation in production areas.
Research & development — Open SDK with C++, Python and ROS for custom robot builds.
TECHNICAL DETAILS
Specifications & capabilities
Key specifications from the manufacturer for the standard and hot-swap battery versions. Final specifications depend on the selected configuration.
Body & payload
Dimensions (standard / hot-swap) — 570×520×320 / 690×600×316 mm
Weight — 80 / 95 kg
Rated payload — 150 kg (max. 200 kg)
Mounting deck height — 236 / 65 mm
Turning diameter — 720 / 830 mm
Power output — 48 V / 30 A (hot-swap: max. 110 A)
Mobility & battery
Speed (default / max.) — 1.0 / 1.5 m/s
Climbing / step / gap — 10° / 40 mm / 40 mm
Stopping accuracy — ±20 mm, ±1°
Battery — 48 V LFP, 1 × 30 Ah / 2 × 15 Ah
Operating time — 8 h
Charging — 3 h, automatic or manual / battery swap
Perception & software
Front & rear LiDAR · Depth cameras · Ultrasonic sensors · ROS / ROS 2
SLAM mapping, path planning, obstacle avoidance and multi-robot scheduling. SDKs for C++ and Python; 3D LiDAR optional.
CONFIGURATION & ENQUIRIES
Tell us about your application
We help clarify the product configuration and coordinate technical questions with the manufacturer.
01 Product selection
Discuss payload, upper structure, mounting interfaces and your operating environment.
02 Technical coordination
Review interfaces, software needs and integration requirements.
03 Project follow-up
Discuss delivery, documentation and support arrangements.